#include <FlyWheel.hpp>
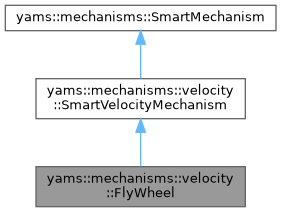
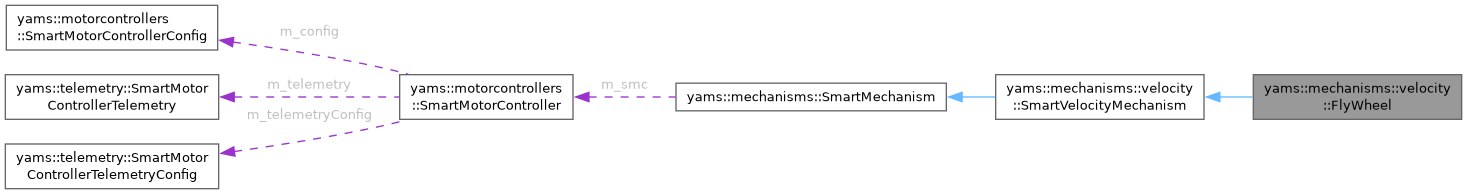
Public Member Functions | |
| FlyWheel (config::FlyWheelConfig *config, motorcontrollers::SmartMotorController *smc) | |
| void | SimIterate () override |
| void | UpdateTelemetry () override |
| void | VisualizationUpdate () override |
| std::string | GetName () const override |
| wpi::cmd::Trigger | Max () override |
| wpi::cmd::Trigger | Min () override |
| wpi::units::degrees_per_second_t | GetVelocity () const |
| wpi::cmd::CommandPtr | Run (wpi::units::degrees_per_second_t velocity) |
| wpi::cmd::CommandPtr | Run (std::function< wpi::units::degrees_per_second_t()> velocity) |
| wpi::cmd::CommandPtr | Run (wpi::units::meters_per_second_t surfaceSpeed) |
| wpi::cmd::CommandPtr | Run (std::function< wpi::units::meters_per_second_t()> surfaceSpeed) |
| wpi::cmd::CommandPtr | RunTo (wpi::units::degrees_per_second_t velocity, wpi::units::degrees_per_second_t tolerance=wpi::units::degrees_per_second_t{5.0}) |
| wpi::cmd::CommandPtr | RunTo (std::function< wpi::units::degrees_per_second_t()> velocity, wpi::units::degrees_per_second_t tolerance=wpi::units::degrees_per_second_t{5.0}) |
| wpi::cmd::CommandPtr | RunTo (wpi::units::meters_per_second_t velocity, wpi::units::meters_per_second_t tolerance) |
| wpi::cmd::CommandPtr | RunTo (std::function< wpi::units::meters_per_second_t()> velocity, wpi::units::meters_per_second_t tolerance) |
| wpi::cmd::Trigger | Gte (wpi::units::degrees_per_second_t velocity) |
| wpi::cmd::Trigger | Lte (wpi::units::degrees_per_second_t velocity) |
| wpi::cmd::Trigger | Between (wpi::units::degrees_per_second_t start, wpi::units::degrees_per_second_t end) |
| wpi::cmd::Trigger | IsNear (wpi::units::degrees_per_second_t velocity, wpi::units::degrees_per_second_t within=wpi::units::degrees_per_second_t{5.0}) const |
| void | SetVelocity (wpi::units::degrees_per_second_t velocity) |
| void | SetSurfaceSpeed (wpi::units::meters_per_second_t speed) |
| void | SetMeasurementVelocitySetpoint (wpi::units::meters_per_second_t velocity) |
| wpi::math::Pose3d | GetPose3d () const override |
| const config::FlyWheelConfig & | GetConfig () const |
| Public Member Functions inherited from yams::mechanisms::velocity::SmartVelocityMechanism | |
| SmartVelocityMechanism () | |
| virtual | ~SmartVelocityMechanism ()=default |
| wpi::MechanismLigament2d * | GetMechanismLigament () |
| wpi::MechanismRoot2d * | GetMechanismRoot () |
| motorcontrollers::SmartMotorController * | GetMotor () |
| Public Member Functions inherited from yams::mechanisms::SmartMechanism | |
| SmartMechanism () | |
| virtual | ~SmartMechanism ()=default |
| wpi::cmd::CommandPtr | Set (double dutycycle) |
| wpi::cmd::CommandPtr | Set (std::function< double()> dutycycle) |
| wpi::cmd::CommandPtr | SetVoltage (wpi::units::volt_t volts) |
| wpi::cmd::CommandPtr | SetVoltage (std::function< wpi::units::volt_t()> volts) |
| void | SetMechanismVelocitySetpoint (wpi::units::turns_per_second_t velocity) |
| void | SetMeasurementVelocitySetpoint (wpi::units::meters_per_second_t velocity) |
| void | SetMechanismPositionSetpoint (wpi::units::turn_t angle) |
| void | SetMeasurementPositionSetpoint (wpi::units::meter_t distance) |
| void | SetVoltageSetpoint (wpi::units::volt_t voltage) |
| void | SetDutyCycleSetpoint (double dutycycle) |
| motorcontrollers::SmartMotorController * | GetMotorController () |
| std::optional< wpi::units::turn_t > | GetMechanismSetpoint () |
| std::optional< wpi::units::meter_t > | GetMeasurementSetpoint () |
| wpi::Mechanism2d * | GetMechanismWindow () |
Additional Inherited Members | |
| Protected Member Functions inherited from yams::mechanisms::SmartMechanism | |
| void | PublishMechanismWindow () |
| Protected Attributes inherited from yams::mechanisms::velocity::SmartVelocityMechanism | |
| wpi::MechanismRoot2d * | m_mechanismRoot {nullptr} |
| wpi::MechanismLigament2d * | m_mechanismLigament {nullptr} |
| Protected Attributes inherited from yams::mechanisms::SmartMechanism | |
| wpi::cmd::SubsystemBase * | m_subsystem {nullptr} |
| motorcontrollers::SmartMotorController * | m_smc {nullptr} |
| std::optional< wpi::Mechanism2d > | m_mechanismWindow |
Detailed Description
Smart mechanism implementation for a flywheel (velocity-controlled roller).
Drives a spinning element using a SmartMotorController configured for mechanism-space (degrees/second) closed-loop velocity control. If a roller diameter is provided, surface-speed commands and reads are also supported.
Example usage (inside a subsystem constructor)
Constructor & Destructor Documentation
◆ FlyWheel()
| yams::mechanisms::velocity::FlyWheel::FlyWheel | ( | config::FlyWheelConfig * | config, |
| motorcontrollers::SmartMotorController * | smc ) |
Construct a FlyWheel from a FlyWheelConfig and a SmartMotorController.
- Parameters
-
config Pointer to the flywheel configuration (must outlive this object). smc Pointer to the motor controller (must outlive this object).
Member Function Documentation
◆ Between()
| wpi::cmd::Trigger yams::mechanisms::velocity::FlyWheel::Between | ( | wpi::units::degrees_per_second_t | start, |
| wpi::units::degrees_per_second_t | end ) |
Trigger that fires while the flywheel angular velocity is between start and end (inclusive).
- Parameters
-
start Lower bound. end Upper bound.
- Returns
- Trigger for the range condition.
◆ GetConfig()
| const config::FlyWheelConfig & yams::mechanisms::velocity::FlyWheel::GetConfig | ( | ) | const |
Get the configuration used to construct this flywheel.
- Returns
- Const reference to the FlyWheelConfig.
◆ GetName()
|
overridevirtual |
Get the human-readable name of this flywheel.
Implements yams::mechanisms::SmartMechanism.
◆ GetPose3d()
|
overridevirtual |
Get the flywheel's pose, for publishing to AdvantageScope as a component of a robot model: where its axle is mounted, as set in its MechanismPositionConfig, turned by the wheel's position about the axis normal to its movement plane.
- Returns
- The pose of the flywheel, relative to the robot.
Implements yams::mechanisms::SmartMechanism.
◆ GetVelocity()
| wpi::units::degrees_per_second_t yams::mechanisms::velocity::FlyWheel::GetVelocity | ( | ) | const |
Get the current angular velocity of the flywheel.
- Returns
- Current mechanism velocity in degrees per second.
◆ Gte()
| wpi::cmd::Trigger yams::mechanisms::velocity::FlyWheel::Gte | ( | wpi::units::degrees_per_second_t | velocity | ) |
Trigger that fires while the flywheel angular velocity is >= the given velocity.
- Parameters
-
velocity Reference angular velocity.
- Returns
- Trigger for the >= condition.
◆ IsNear()
| wpi::cmd::Trigger yams::mechanisms::velocity::FlyWheel::IsNear | ( | wpi::units::degrees_per_second_t | velocity, |
| wpi::units::degrees_per_second_t | within = wpi::units::degrees_per_second_t{5.0} ) const |
Trigger that fires while the flywheel is within tolerance of a velocity.
- Parameters
-
velocity Reference angular velocity. within Tolerance.
- Returns
- Trigger for the near condition.
◆ Lte()
| wpi::cmd::Trigger yams::mechanisms::velocity::FlyWheel::Lte | ( | wpi::units::degrees_per_second_t | velocity | ) |
Trigger that fires while the flywheel angular velocity is <= the given velocity.
- Parameters
-
velocity Reference angular velocity.
- Returns
- Trigger for the <= condition.
◆ Max()
|
overridevirtual |
Trigger that becomes true when the flywheel is at or above its maximum configured velocity.
- Returns
- Trigger for the upper velocity limit.
Implements yams::mechanisms::velocity::SmartVelocityMechanism.
◆ Min()
|
overridevirtual |
Trigger that becomes true when the flywheel is at or below its minimum configured velocity (e.g. stalled or reversed).
- Returns
- Trigger for the lower velocity limit.
Implements yams::mechanisms::velocity::SmartVelocityMechanism.
◆ Run() [1/4]
| wpi::cmd::CommandPtr yams::mechanisms::velocity::FlyWheel::Run | ( | std::function< wpi::units::degrees_per_second_t()> | velocity | ) |
Set the flywheel to the given angular velocity via a supplier.
- Parameters
-
velocity Supplier returning the desired angular velocity each loop.
- Returns
- CommandPtr that sets the flywheel to the desired speed.
◆ Run() [2/4]
| wpi::cmd::CommandPtr yams::mechanisms::velocity::FlyWheel::Run | ( | std::function< wpi::units::meters_per_second_t()> | surfaceSpeed | ) |
Set the flywheel to the given surface speed via a supplier.
Requires that a roller diameter was provided in the config.
- Parameters
-
surfaceSpeed Supplier returning the desired surface speed each loop.
- Returns
- CommandPtr that sets the flywheel to the desired surface speed.
◆ Run() [3/4]
| wpi::cmd::CommandPtr yams::mechanisms::velocity::FlyWheel::Run | ( | wpi::units::degrees_per_second_t | velocity | ) |
Set the flywheel to the given angular velocity.
- Parameters
-
velocity FlyWheel angular velocity to go to.
- Returns
- CommandPtr that sets the flywheel to the desired speed.
◆ Run() [4/4]
| wpi::cmd::CommandPtr yams::mechanisms::velocity::FlyWheel::Run | ( | wpi::units::meters_per_second_t | surfaceSpeed | ) |
Set the flywheel to the given surface speed.
Requires that a roller diameter was provided in the config.
- Parameters
-
surfaceSpeed Desired surface speed in metres per second.
- Returns
- CommandPtr that sets the flywheel to the desired surface speed.
◆ RunTo() [1/4]
| wpi::cmd::CommandPtr yams::mechanisms::velocity::FlyWheel::RunTo | ( | std::function< wpi::units::degrees_per_second_t()> | velocity, |
| wpi::units::degrees_per_second_t | tolerance = wpi::units::degrees_per_second_t{5.0} ) |
Run the flywheel to a supplier-provided angular velocity within a tolerance, then end the command.
The supplier is read every loop and sent as the setpoint, so a target that changes while the command runs is followed. The command ends once the mechanism has been within tolerance of the supplier's current value for 0.1 s.
- Parameters
-
velocity Supplier returning the target angular velocity. tolerance Allowable error.
- Returns
- CommandPtr that ends once the flywheel is near the target velocity.
- Note
- Do not use with a default command on the subsystem, as it will override the setting after this ends.
◆ RunTo() [2/4]
| wpi::cmd::CommandPtr yams::mechanisms::velocity::FlyWheel::RunTo | ( | std::function< wpi::units::meters_per_second_t()> | velocity, |
| wpi::units::meters_per_second_t | tolerance ) |
Run the flywheel to a supplier-provided surface speed within a tolerance, then end the command.
Requires that a roller diameter was provided in the config.
- Parameters
-
velocity Supplier returning the target surface speed. tolerance Allowable error.
- Returns
- CommandPtr that ends once the flywheel is near the target surface speed.
- Note
- Do not use with a default command on the subsystem, as it will override the setting after this ends.
◆ RunTo() [3/4]
| wpi::cmd::CommandPtr yams::mechanisms::velocity::FlyWheel::RunTo | ( | wpi::units::degrees_per_second_t | velocity, |
| wpi::units::degrees_per_second_t | tolerance = wpi::units::degrees_per_second_t{5.0} ) |
Run the flywheel to an angular velocity within a tolerance, then end the command.
- Parameters
-
velocity Target angular velocity. tolerance Allowable error.
- Returns
- CommandPtr that ends once the flywheel is near the target velocity.
- Note
- Do not use with a default command on the subsystem, as it will override the setting after this ends.
◆ RunTo() [4/4]
| wpi::cmd::CommandPtr yams::mechanisms::velocity::FlyWheel::RunTo | ( | wpi::units::meters_per_second_t | velocity, |
| wpi::units::meters_per_second_t | tolerance ) |
Run the flywheel to a surface speed within a tolerance, then end the command.
Requires that a roller diameter was provided in the config.
- Parameters
-
velocity Target surface speed. tolerance Allowable error.
- Returns
- CommandPtr that ends once the flywheel is near the target surface speed.
- Note
- Do not use with a default command on the subsystem, as it will override the setting after this ends.
◆ SetMeasurementVelocitySetpoint()
| void yams::mechanisms::velocity::FlyWheel::SetMeasurementVelocitySetpoint | ( | wpi::units::meters_per_second_t | velocity | ) |
Set flywheel velocity from a linear surface speed (base-class override).
Converts the surface speed to angular velocity using the configured roller diameter. Requires roller diameter to be configured; no-op otherwise.
- Parameters
-
velocity Desired surface speed.
◆ SetSurfaceSpeed()
| void yams::mechanisms::velocity::FlyWheel::SetSurfaceSpeed | ( | wpi::units::meters_per_second_t | speed | ) |
Directly command the flywheel to a surface speed setpoint (non-command).
Requires roller diameter to be configured; no-op otherwise.
- Parameters
-
speed Desired surface speed.
◆ SetVelocity()
| void yams::mechanisms::velocity::FlyWheel::SetVelocity | ( | wpi::units::degrees_per_second_t | velocity | ) |
Directly command the flywheel to an angular velocity setpoint (non-command).
- Parameters
-
velocity Desired angular velocity.
◆ SimIterate()
|
overridevirtual |
Advance the flywheel's simulation by one loop iteration.
Implements yams::mechanisms::SmartMechanism.
◆ UpdateTelemetry()
|
overridevirtual |
Publish flywheel telemetry to NetworkTables / SmartDashboard.
Implements yams::mechanisms::SmartMechanism.
◆ VisualizationUpdate()
|
overridevirtual |
Update the Mechanism2d ligament to reflect the current velocity.
Implements yams::mechanisms::SmartMechanism.
The documentation for this class was generated from the following file:
- /home/runner/work/YAMS/YAMS/yams/cpp/include/yams/mechanisms/velocity/FlyWheel.hpp
