#include <A301Wrapper.hpp>
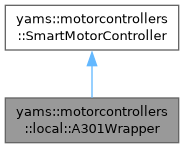
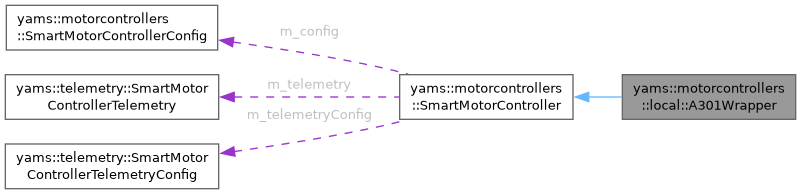
Public Member Functions | |
| A301Wrapper (first::a301::A301 *a301, SmartMotorControllerConfig *config) | |
| ~A301Wrapper () | |
| bool | ApplyConfig (const SmartMotorControllerConfig &config) override |
| void | SetupSimulation () override |
| void | SimIterate () override |
| void | SeedRelativeEncoder () override |
| void | SynchronizeRelativeEncoder () override |
| void | SetDutyCycle (double dutyCycle) override |
| double | GetDutyCycle () override |
| void | SetVoltage (wpi::units::volt_t voltage) override |
| wpi::units::volt_t | GetVoltage () override |
| void | SetPosition (wpi::units::turn_t angle) override |
| void | SetPosition (wpi::units::meter_t distance) override |
| void | SetVelocity (wpi::units::turns_per_second_t velocity) override |
| void | SetVelocity (wpi::units::turns_per_second_t velocity, wpi::units::newton_t feedforwardForce) override |
| void | SetVelocity (wpi::units::meters_per_second_t velocity) override |
| void | SetEncoderPosition (wpi::units::turn_t angle) override |
| void | SetEncoderPosition (wpi::units::meter_t distance) override |
| void | SetEncoderVelocity (wpi::units::turns_per_second_t velocity) override |
| void | SetEncoderVelocity (wpi::units::meters_per_second_t velocity) override |
| wpi::units::turn_t | GetMechanismPosition () override |
| wpi::units::turns_per_second_t | GetMechanismVelocity () override |
| wpi::units::turn_t | GetRelativeMechanismPosition () override |
| wpi::units::turns_per_second_t | GetRelativeMechanismVelocity () override |
| wpi::units::turns_per_second_squared_t | GetMechanismAcceleration () override |
| wpi::units::turn_t | GetRotorPosition () override |
| wpi::units::turns_per_second_t | GetRotorVelocity () override |
| wpi::units::meter_t | GetMeasurementPosition () override |
| wpi::units::meters_per_second_t | GetMeasurementVelocity () override |
| wpi::units::meters_per_second_squared_t | GetMeasurementAcceleration () override |
| std::optional< wpi::units::turn_t > | GetExternalEncoderMechanismPosition () override |
| std::optional< wpi::units::turns_per_second_t > | GetExternalEncoderMechanismVelocity () override |
| std::optional< wpi::units::ampere_t > | GetSupplyCurrent () override |
| wpi::units::ampere_t | GetStatorCurrent () override |
| wpi::units::celsius_t | GetTemperature () override |
| wpi::math::DCMotor | GetDCMotor () override |
| void | SetZeroPower (MotorMode mode) override |
| void | SetMotorInverted (bool inverted) override |
| void | SetEncoderInverted (bool inverted) override |
| void | SetKp (double kP) override |
| void | SetKi (double kI) override |
| void | SetKd (double kD) override |
| void | SetFeedback (double kP, double kI, double kD) override |
| void | SetKs (double kS) override |
| void | SetKv (double kV) override |
| void | SetKa (double kA) override |
| void | SetKg (double kG) override |
| void | SetFeedforward (double kS, double kV, double kA, double kG) override |
| void | SetStatorCurrentLimit (wpi::units::ampere_t currentLimit) override |
| void | SetSupplyCurrentLimit (wpi::units::ampere_t currentLimit) override |
| void | SetClosedLoopRampRate (wpi::units::second_t rampRate) override |
| void | SetOpenLoopRampRate (wpi::units::second_t rampRate) override |
| void | SetMechanismUpperLimit (wpi::units::turn_t upperLimit) override |
| void | SetMechanismLowerLimit (wpi::units::turn_t lowerLimit) override |
| void | SetMechanismLimits (wpi::units::turn_t lower, wpi::units::turn_t upper) override |
| void | SetMechanismLimitsEnabled (bool enabled) override |
| void | SetMeasurementUpperLimit (wpi::units::meter_t upperLimit) override |
| void | SetMeasurementLowerLimit (wpi::units::meter_t lowerLimit) override |
| void | SetMotionProfileMaxVelocity (wpi::units::turns_per_second_t maxVelocity) override |
| void | SetMotionProfileMaxVelocity (wpi::units::meters_per_second_t maxVelocity) override |
| void | SetMotionProfileMaxAcceleration (wpi::units::turns_per_second_squared_t maxAcc) override |
| void | SetMotionProfileMaxAcceleration (wpi::units::meters_per_second_squared_t maxAcc) override |
| void | SetMotionProfileMaxJerk (wpi::units::angular_jerk::turns_per_second_cubed_t maxJerk) override |
| void | SetExponentialProfile (std::optional< double > kV, std::optional< double > kA, std::optional< wpi::units::volt_t > maxInput) override |
| void | SetClosedLoopSlot (ClosedLoopControllerSlot slot) override |
| void | SetMechanismGearing (const gearing::MechanismGearing &gearing) override |
| void | SetMechanismCircumference (wpi::units::meter_t circumference) override |
| SmartMotorControllerConfig & | GetConfig () override |
| void * | GetMotorController () override |
| void * | GetMotorControllerConfig () override |
| telemetry::UnsupportedTelemetryFields | GetUnsupportedTelemetryFields () override |
| void | SetVelocity (wpi::units::meters_per_second_t velocity, wpi::units::newton_t feedforwardForce) |
| Public Member Functions inherited from yams::motorcontrollers::SmartMotorController | |
| virtual | ~SmartMotorController () |
| virtual void | SetSimSupplier (std::shared_ptr< SimSupplier > supplier) |
| SimSupplier * | GetSimSupplier () const |
| void | SetVelocity (wpi::units::meters_per_second_t velocity, wpi::units::newton_t feedforwardForce) |
| wpi::math::DCMotor | GetMechanismDCMotor () |
| void | SetMechanismSimSupplier (std::shared_ptr< SimSupplier > supplier) |
| double | GetMechanismDutyCycle (double dutyCycle) |
| wpi::units::second_t | GetClosedLoopControllerPeriod () const |
| virtual std::optional< wpi::units::second_t > | GetVelocityMeasurementDelay () const |
| void | StartClosedLoopController () |
| void | StopClosedLoopController () |
| bool | IsClosedLoopControllerStopped () const |
| math::LQRController * | GetLQRController () |
| math::ADRCController * | GetADRCController () |
| void | IterateClosedLoopController () |
| void | SetupTelemetry (std::shared_ptr< wpi::nt::NetworkTable > dataTable, std::shared_ptr< wpi::nt::NetworkTable > tuningTable) |
| void | SetupTelemetry () |
| void | SetupLiveTuning () |
| void | UpdateTelemetry () |
| bool | TuningEnabled () const |
| void | ApplyTuningValues () |
| void | StopLiveTuning () |
| const std::vector< SmartMotorController * > & | GetLooselyCoupledFollowers () const |
| void | AddCloseHook (std::function< void()> hook) |
| SmartMotorController & | WithTelemetry (telemetry::SmartMotorControllerTelemetryConfig config) |
| ClosedLoopControllerSlot | GetClosedLoopControllerSlot () const |
| std::optional< wpi::units::turn_t > | GetMechanismPositionSetpoint () const |
| std::optional< wpi::units::turns_per_second_t > | GetMechanismSetpointVelocity () const |
| std::optional< wpi::units::meter_t > | GetMeasurementPositionSetpoint () const |
| std::optional< wpi::units::meters_per_second_t > | GetMeasurementSetpointVelocity () const |
| std::optional< wpi::units::newton_t > | GetSetpointFeedforwardForce () const |
| std::string | GetName () const |
| bool | IsMotor (const wpi::math::DCMotor &a, const wpi::math::DCMotor &b) const |
| void | CheckConfigSafety () |
| void | Close () |
Additional Inherited Members | |
| Public Types inherited from yams::motorcontrollers::SmartMotorController | |
| using | ClosedLoopControllerSlot = SmartMotorControllerConfig::ClosedLoopControllerSlot |
| using | MotorMode = SmartMotorControllerConfig::MotorMode |
| using | ControlMode = SmartMotorControllerConfig::ControlMode |
| Protected Member Functions inherited from yams::motorcontrollers::SmartMotorController | |
| SmartMotorController () | |
| void | LoadLooselyCoupledFollowers () |
| void | Follow (SmartMotorController &leader, bool inverted) |
| double | CalculateSimDutyCycle (double dutyCycle) |
| void | ConfigureSoftwarePID (const SmartMotorControllerConfig &config) |
| void | ForwardPositionToFollowers (wpi::units::turn_t pos) |
| void | ForwardPositionToFollowers (wpi::units::meter_t dist) |
| void | ForwardVelocityToFollowers (wpi::units::turns_per_second_t vel) |
| void | ForwardVelocityToFollowers (wpi::units::meters_per_second_t vel) |
| bool | UsesSystemCoreController () const |
| void | ApplyADRCConfig (const SmartMotorControllerConfig &config) |
| const void * | BatterySimKey () const |
| Protected Attributes inherited from yams::motorcontrollers::SmartMotorController | |
| SmartMotorControllerConfig * | m_config {nullptr} |
| ClosedLoopControllerSlot | m_slot {ClosedLoopControllerSlot::SLOT_0} |
| std::shared_ptr< SimSupplier > | m_simSupplier |
| std::vector< SmartMotorController * > | m_looseFollowers |
| bool | m_iteratedByLeader {false} |
| bool | m_simulatesMechanism {false} |
| std::optional< wpi::math::PIDController > | m_pid |
| std::optional< math::LQRController > | m_lqr |
| std::optional< math::ADRCController > | m_adrc |
| std::optional< wpi::math::TrapezoidProfile< wpi::units::turns >::State > | m_trapState |
| std::optional< wpi::math::ExponentialProfile< wpi::units::turns, wpi::units::volts >::State > | m_expoState |
| std::optional< wpi::math::TrapezoidProfile< wpi::units::meters >::State > | m_linearTrapState |
| std::optional< wpi::math::ExponentialProfile< wpi::units::meters, wpi::units::volts >::State > | m_linearExpoState |
| std::optional< wpi::units::turn_t > | m_lastClosedLoopMechanismPosition |
| std::optional< double > | m_lastClosedLoopVoltage |
| std::optional< wpi::units::turn_t > | m_setpointPosition |
| std::optional< wpi::units::turns_per_second_t > | m_setpointVelocity |
| std::optional< wpi::units::newton_t > | m_setpointFeedforwardForce |
| std::vector< std::function< void()> > | m_closeHooks |
| std::unique_ptr< wpi::Notifier > | m_closedLoopControllerThread |
| bool | m_closedLoopControllerRunning {false} |
| std::shared_ptr< wpi::nt::NetworkTable > | m_parentTable |
| std::shared_ptr< wpi::nt::NetworkTable > | m_telemetryTable |
| std::shared_ptr< wpi::nt::NetworkTable > | m_tuningTable |
| telemetry::SmartMotorControllerTelemetry | m_telemetry |
| telemetry::SmartMotorControllerTelemetryConfig | m_telemetryConfig |
| bool | m_telemetryConfigExplicit {false} |
| std::shared_ptr< telemetry::SmartMotorControllerTelemetryConfig > | m_specifiedTelemetryConfig |
| bool | m_liveTuningRegistered {false} |
| bool | m_closed {false} |
| Static Protected Attributes inherited from yams::motorcontrollers::SmartMotorController | |
| static constexpr double | kClosedLoopRampFullScaleVolts = 12.0 |
Detailed Description
SmartMotorController implementation for the FIRST A301 smart motor, using REVLib 2027.
The A301 has no closed loop gains, so the closed loop controller runs on the SystemCore and commands the A301 with voltage. It also has no current limits, ramp rates or voltage compensation, and configuring them throws a SmartMotorControllerConfigurationException.
The gearing given to WithMotorGearing is from the A301's rotor to the mechanism: usually the gearbox attached to the A301, and any gearing after it. Each A301 has one motor, YMotors::A301().
Followers: the A301 has no follower mode, so the wrapper follows in software. Wrap each other A301 on the mechanism in its own A301Wrapper and give them to the main A301's WithFollowers, as (A301Wrapper*, inverted) pairs. Only an A301Wrapper can follow an A301. The main A301 sends each follower its voltage or duty cycle, and its GetDCMotor() and simulation have every A301, so a follower does not simulate itself or draw current from BatterySim: it reads the main A301's simulation, and the main A301's SimIterate() iterates it. Create each follower before the main A301, and destroy it after. WithLooselyCoupledFollowers still works as on any motor controller, for motors with their own load.
REVLib does not simulate the A301, so in simulation the wrapper drives a DCMotorSim.
External encoder: the A301's own absolute encoder, on its output shaft, used by giving the first::a301::A301* itself to WithExternalEncoder. Its gearing, given to WithExternalEncoderGearing, is from the output shaft to the mechanism. Its zero offset, inversion and wrapping range are applied by the wrapper; without WithWrapping it reads [0, 1) rotations of the encoder.
Example usage (inside a subsystem constructor)
Constructor & Destructor Documentation
◆ A301Wrapper()
| yams::motorcontrollers::local::A301Wrapper::A301Wrapper | ( | first::a301::A301 * | a301, |
| SmartMotorControllerConfig * | config ) |
Construct an A301Wrapper around a FIRST A301.
- Parameters
-
a301 Pointer to the A301 hardware object (must outlive this wrapper). config Pointer to the SmartMotorControllerConfig (must outlive this wrapper).
◆ ~A301Wrapper()
| yams::motorcontrollers::local::A301Wrapper::~A301Wrapper | ( | ) |
Member Function Documentation
◆ ApplyConfig()
|
overridevirtual |
Apply a SmartMotorControllerConfig to the underlying hardware.
- Parameters
-
config Configuration to apply.
- Returns
- true if the configuration was applied successfully.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetConfig()
|
overridevirtual |
Get a mutable reference to the current configuration.
- Returns
- Reference to the SmartMotorControllerConfig.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetDCMotor()
|
overridevirtual |
Get the DC motor model associated with this controller.
- Returns
- wpi::math::DCMotor model.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetDutyCycle()
|
overridevirtual |
Get the current motor duty cycle.
- Returns
- Duty cycle in [-1, 1].
Implements yams::motorcontrollers::SmartMotorController.
◆ GetExternalEncoderMechanismPosition()
|
overridevirtual |
Get the mechanism position from the external (absolute) encoder (applies the external encoder gearing). Available whether or not the external encoder is used for feedback.
- Returns
- Mechanism position in turns from the external encoder, or empty if none is attached.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetExternalEncoderMechanismVelocity()
|
overridevirtual |
The A301 does not report its absolute encoder's velocity, so this is the A301's relative encoder's velocity at the mechanism, or empty without the absolute encoder.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetMeasurementAcceleration()
|
overridevirtual |
Get the linear measurement acceleration.
- Returns
- Linear acceleration in meters per second squared.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetMeasurementPosition()
|
overridevirtual |
Get the linear measurement position (applies circumference conversion).
- Returns
- Linear position in meters.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetMeasurementVelocity()
|
overridevirtual |
Get the linear measurement velocity (applies circumference conversion).
- Returns
- Linear velocity in meters per second.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetMechanismAcceleration()
|
overridevirtual |
Get the mechanism acceleration (derived from velocity).
- Returns
- Mechanism acceleration in turns per second squared.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetMechanismPosition()
|
overridevirtual |
Get the mechanism position (applies gearing). Uses the external (absolute) encoder when one is configured with SmartMotorControllerConfig::WithUseExternalFeedbackEncoder(), otherwise the relative encoder. Use GetRelativeMechanismPosition() to only read the relative encoder.
- Returns
- Mechanism position in turns.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetMechanismVelocity()
|
overridevirtual |
The A301 does not report its absolute encoder's velocity, so this is the A301's relative encoder's velocity at the mechanism.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetMotorController()
|
overridevirtual |
Get a raw pointer to the underlying A301.
- Returns
- Pointer to the first::a301::A301 instance.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetMotorControllerConfig()
|
overridevirtual |
The A301 has no vendor config.
- Returns
- nullptr.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetRelativeMechanismPosition()
|
overridevirtual |
Get the mechanism position from the relative encoder in the motor (applies gearing). Never uses the external (absolute) encoder.
- Returns
- Mechanism position in turns from the relative encoder.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetRelativeMechanismVelocity()
|
overridevirtual |
Get the mechanism velocity from the relative encoder in the motor (applies gearing). Never uses the external (absolute) encoder.
- Returns
- Mechanism velocity in turns per second from the relative encoder.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetRotorPosition()
|
overridevirtual |
Get the raw rotor position (no gearing applied).
- Returns
- Rotor position in turns.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetRotorVelocity()
|
overridevirtual |
Get the raw rotor velocity (no gearing applied).
- Returns
- Rotor velocity in turns per second.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetStatorCurrent()
|
overridevirtual |
Get the stator (output) current draw.
- Returns
- Stator current.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetSupplyCurrent()
|
overridevirtual |
The simulated supply current, or empty on the robot, since the A301 does not report it.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetTemperature()
|
overridevirtual |
Get the motor controller temperature.
- Returns
- Temperature in degrees Celsius.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetUnsupportedTelemetryFields()
|
overridevirtual |
Supply current, current limits and ramp rates, which the A301 does not have.
Reimplemented from yams::motorcontrollers::SmartMotorController.
◆ GetVoltage()
|
overridevirtual |
Get the voltage currently applied to the motor.
- Returns
- Applied voltage.
Implements yams::motorcontrollers::SmartMotorController.
◆ SeedRelativeEncoder()
|
overridevirtual |
Seed the relative encoder from the absolute sensor position (one-shot on startup).
Implements yams::motorcontrollers::SmartMotorController.
◆ SetClosedLoopRampRate()
|
overridevirtual |
The closed loop runs on the SystemCore, which ramps its output.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetClosedLoopSlot()
|
overridevirtual |
Select the active closed-loop gain slot.
- Parameters
-
slot Gain slot to activate.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetDutyCycle()
|
overridevirtual |
Command a duty-cycle output to the motor.
- Parameters
-
dutyCycle Normalized duty cycle in [-1, 1].
Implements yams::motorcontrollers::SmartMotorController.
◆ SetEncoderInverted()
|
overridevirtual |
The A301's internal encoder cannot be inverted; always throws std::runtime_error.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetEncoderPosition() [1/2]
|
overridevirtual |
Write a linear distance into the encoder (seeds the position).
- Parameters
-
distance Linear distance to write.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetEncoderPosition() [2/2]
|
overridevirtual |
Write a mechanism angle into the encoder (seeds the position).
- Parameters
-
angle Mechanism angle to write.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetEncoderVelocity() [1/2]
|
overridevirtual |
Linear version of SetEncoderVelocity(turns_per_second_t); throws without a mechanism circumference.
- Parameters
-
velocity Mechanism linear velocity.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetEncoderVelocity() [2/2]
|
overridevirtual |
Set the simulated mechanism velocity. Throws std::runtime_error outside of simulation, since the A301 does not support setting the encoder velocity.
- Parameters
-
velocity Mechanism velocity.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetExponentialProfile()
|
overridevirtual |
Update the exponential profile. Missing values keep the configured ones.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetFeedback()
|
overridevirtual |
Set all three PID feedback gains at once (live update).
- Parameters
-
kP Proportional gain. kI Integral gain. kD Derivative gain.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetFeedforward()
|
overridevirtual |
Set all four feedforward gains at once (live update).
- Parameters
-
kS Static friction voltage. kV Velocity feedforward coefficient. kA Acceleration feedforward coefficient. kG Gravity feedforward coefficient.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetKa()
|
overridevirtual |
Set the acceleration feedforward coefficient (live update).
- Parameters
-
kA Acceleration feedforward coefficient.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetKd()
|
overridevirtual |
Set the derivative gain (live update).
- Parameters
-
kD Derivative gain.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetKg()
|
overridevirtual |
Set the gravity feedforward coefficient (live update).
- Parameters
-
kG Gravity feedforward coefficient.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetKi()
|
overridevirtual |
Set the integral gain (live update).
- Parameters
-
kI Integral gain.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetKp()
|
overridevirtual |
Set the proportional gain (live update).
- Parameters
-
kP Proportional gain.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetKs()
|
overridevirtual |
Set the static friction feedforward (live update).
- Parameters
-
kS Static friction voltage.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetKv()
|
overridevirtual |
Set the velocity feedforward coefficient (live update).
- Parameters
-
kV Velocity feedforward coefficient.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetMeasurementLowerLimit()
|
overridevirtual |
Set the lower linear soft limit for the measurement.
- Parameters
-
lowerLimit Lower distance limit.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetMeasurementUpperLimit()
|
overridevirtual |
Set the upper linear soft limit for the measurement.
- Parameters
-
upperLimit Upper distance limit.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetMechanismCircumference()
|
overridevirtual |
Update the mechanism circumference used for linear position/velocity conversions.
The base implementation updates the config; wrappers override it to also reconfigure the hardware.
- Parameters
-
circumference New mechanism circumference.
Reimplemented from yams::motorcontrollers::SmartMotorController.
◆ SetMechanismGearing()
|
overridevirtual |
Update the mechanism gearing and rebuild the simulated motor, which depends on it.
- Parameters
-
gearing New mechanism gearing.
Reimplemented from yams::motorcontrollers::SmartMotorController.
◆ SetMechanismLimits()
|
overridevirtual |
Set both angular soft limits for the mechanism.
- Parameters
-
lower Lower angle limit. upper Upper angle limit.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetMechanismLimitsEnabled()
|
overridevirtual |
The closed loop controller on the SystemCore enforces the mechanism limits.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetMechanismLowerLimit()
|
overridevirtual |
Set the lower angular soft limit for the mechanism.
- Parameters
-
lowerLimit Lower angle limit.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetMechanismUpperLimit()
|
overridevirtual |
Set the upper angular soft limit for the mechanism.
- Parameters
-
upperLimit Upper angle limit.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetMotionProfileMaxAcceleration() [1/2]
|
overridevirtual |
◆ SetMotionProfileMaxAcceleration() [2/2]
|
overridevirtual |
◆ SetMotionProfileMaxJerk()
|
overridevirtual |
Set the maximum jerk of a velocity trapezoidal profile (its acceleration constraint). Has no effect on position profiles.
- Parameters
-
maxJerk Maximum angular jerk.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetMotionProfileMaxVelocity() [1/2]
|
overridevirtual |
Set the maximum linear velocity for the motion profile.
- Parameters
-
maxVelocity Maximum linear velocity.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetMotionProfileMaxVelocity() [2/2]
|
overridevirtual |
Set the maximum angular velocity for the motion profile.
- Parameters
-
maxVelocity Maximum mechanism angular velocity.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetMotorInverted()
|
overridevirtual |
Set the motor output direction.
- Parameters
-
inverted true to invert the motor direction.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetOpenLoopRampRate()
|
overridevirtual |
The A301 has no ramp rates; always throws std::runtime_error.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetPosition() [1/2]
|
overridevirtual |
Command a linear measurement position setpoint (closed-loop).
- Parameters
-
distance Target linear distance.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetPosition() [2/2]
|
overridevirtual |
Command a mechanism angle position setpoint (closed-loop).
- Parameters
-
angle Target mechanism angle.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetStatorCurrentLimit()
|
overridevirtual |
The A301 has no current limits; always throws std::runtime_error.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetSupplyCurrentLimit()
|
overridevirtual |
The A301 has no current limits; always throws std::runtime_error.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetupSimulation()
|
overridevirtual |
Initialize the DCMotorSim used for simulation.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetVelocity() [1/4]
|
overridevirtual |
Command a linear measurement velocity setpoint (closed-loop).
- Parameters
-
velocity Target linear velocity.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetVelocity() [2/4]
| void yams::motorcontrollers::SmartMotorController::SetVelocity | ( | wpi::units::meters_per_second_t | velocity, |
| wpi::units::newton_t | feedforwardForce ) |
Command a linear velocity setpoint with an additional feedforward force applied on top.
Throws SmartMotorControllerConfigurationException if the mechanism circumference is not configured.
- Parameters
-
velocity Target linear velocity. feedforwardForce Additional feedforward force at the mechanism.
◆ SetVelocity() [3/4]
|
overridevirtual |
Command a mechanism angular velocity setpoint (closed-loop).
- Parameters
-
velocity Target mechanism angular velocity.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetVelocity() [4/4]
|
overridevirtual |
Command a velocity setpoint with an additional feedforward force, added by the SystemCore closed loop.
- Parameters
-
velocity Target mechanism angular velocity. feedforwardForce Additional feedforward force at the mechanism.
Reimplemented from yams::motorcontrollers::SmartMotorController.
◆ SetVoltage()
|
overridevirtual |
Command a voltage output to the motor.
- Parameters
-
voltage Voltage to apply.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetZeroPower()
|
overridevirtual |
Set the idle (neutral) mode of the motor.
- Parameters
-
mode COAST or BRAKE.
Implements yams::motorcontrollers::SmartMotorController.
◆ SimIterate()
|
overridevirtual |
Advance the motor simulation by one loop iteration. Each motor controller's SimIterate() calls this last, with SmartMotorController::SimIterate(): it iterates the loosely coupled followers reading this motor controller's mechanism's simulation, which a mechanism steps right before. Each follower's iterates its own.
Reimplemented from yams::motorcontrollers::SmartMotorController.
◆ SynchronizeRelativeEncoder()
|
overridevirtual |
Periodically re-synchronize the relative encoder to the absolute sensor.
Implements yams::motorcontrollers::SmartMotorController.
The documentation for this class was generated from the following file:
- /home/runner/work/YAMS/YAMS/yams/cpp/include/yams/motorcontrollers/local/A301Wrapper.hpp
