#include <NovaWrapper.hpp>
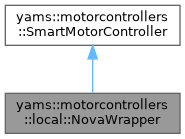
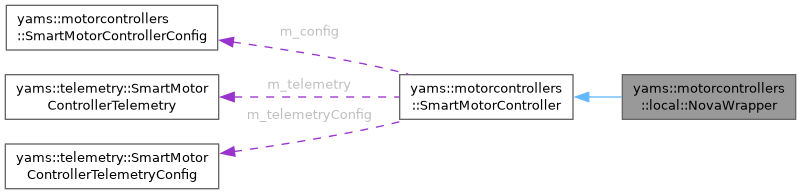
Public Member Functions | |
| NovaWrapper (thrifty::Nova *nova, wpi::math::DCMotor motor, SmartMotorControllerConfig *config) | |
| ~NovaWrapper () | |
| bool | ApplyConfig (const SmartMotorControllerConfig &config) override |
| void | SetupSimulation () override |
| void | SimIterate () override |
| void | SeedRelativeEncoder () override |
| void | SynchronizeRelativeEncoder () override |
| void | SetDutyCycle (double dutyCycle) override |
| double | GetDutyCycle () override |
| void | SetVoltage (wpi::units::volt_t voltage) override |
| wpi::units::volt_t | GetVoltage () override |
| void | SetPosition (wpi::units::turn_t angle) override |
| void | SetPosition (wpi::units::meter_t distance) override |
| void | SetVelocity (wpi::units::turns_per_second_t velocity) override |
| void | SetVelocity (wpi::units::turns_per_second_t velocity, wpi::units::newton_t feedforwardForce) override |
| void | SetVelocity (wpi::units::meters_per_second_t velocity) override |
| void | SetEncoderPosition (wpi::units::turn_t angle) override |
| void | SetEncoderPosition (wpi::units::meter_t distance) override |
| void | SetEncoderVelocity (wpi::units::turns_per_second_t velocity) override |
| void | SetEncoderVelocity (wpi::units::meters_per_second_t velocity) override |
| wpi::units::turn_t | GetMechanismPosition () override |
| wpi::units::turns_per_second_t | GetMechanismVelocity () override |
| wpi::units::turn_t | GetRelativeMechanismPosition () override |
| wpi::units::turns_per_second_t | GetRelativeMechanismVelocity () override |
| wpi::units::turns_per_second_squared_t | GetMechanismAcceleration () override |
| wpi::units::turn_t | GetRotorPosition () override |
| wpi::units::turns_per_second_t | GetRotorVelocity () override |
| wpi::units::meter_t | GetMeasurementPosition () override |
| wpi::units::meters_per_second_t | GetMeasurementVelocity () override |
| wpi::units::meters_per_second_squared_t | GetMeasurementAcceleration () override |
| std::optional< wpi::units::turn_t > | GetExternalEncoderMechanismPosition () override |
| std::optional< wpi::units::turns_per_second_t > | GetExternalEncoderMechanismVelocity () override |
| std::optional< wpi::units::ampere_t > | GetSupplyCurrent () override |
| wpi::units::ampere_t | GetStatorCurrent () override |
| wpi::units::celsius_t | GetTemperature () override |
| wpi::math::DCMotor | GetDCMotor () override |
| void | SetZeroPower (MotorMode mode) override |
| void | SetMotorInverted (bool inverted) override |
| void | SetEncoderInverted (bool inverted) override |
| void | SetKp (double kP) override |
| void | SetKi (double kI) override |
| void | SetKd (double kD) override |
| void | SetFeedback (double kP, double kI, double kD) override |
| void | SetKs (double kS) override |
| void | SetKv (double kV) override |
| void | SetKa (double kA) override |
| void | SetKg (double kG) override |
| void | SetFeedforward (double kS, double kV, double kA, double kG) override |
| void | SetStatorCurrentLimit (wpi::units::ampere_t currentLimit) override |
| void | SetSupplyCurrentLimit (wpi::units::ampere_t currentLimit) override |
| void | SetClosedLoopRampRate (wpi::units::second_t rampRate) override |
| void | SetOpenLoopRampRate (wpi::units::second_t rampRate) override |
| void | SetMechanismUpperLimit (wpi::units::turn_t upperLimit) override |
| void | SetMechanismLowerLimit (wpi::units::turn_t lowerLimit) override |
| void | SetMechanismLimits (wpi::units::turn_t lower, wpi::units::turn_t upper) override |
| void | SetMechanismLimitsEnabled (bool enabled) override |
| void | SetMeasurementUpperLimit (wpi::units::meter_t upperLimit) override |
| void | SetMeasurementLowerLimit (wpi::units::meter_t lowerLimit) override |
| void | SetMotionProfileMaxVelocity (wpi::units::turns_per_second_t maxVelocity) override |
| void | SetMotionProfileMaxVelocity (wpi::units::meters_per_second_t maxVelocity) override |
| void | SetMotionProfileMaxAcceleration (wpi::units::turns_per_second_squared_t maxAcc) override |
| void | SetMotionProfileMaxAcceleration (wpi::units::meters_per_second_squared_t maxAcc) override |
| void | SetMotionProfileMaxJerk (wpi::units::angular_jerk::turns_per_second_cubed_t maxJerk) override |
| void | SetExponentialProfile (std::optional< double > kV, std::optional< double > kA, std::optional< wpi::units::volt_t > maxInput) override |
| void | SetClosedLoopSlot (ClosedLoopControllerSlot slot) override |
| void | SetMechanismGearing (const gearing::MechanismGearing &gearing) override |
| void | SetMechanismCircumference (wpi::units::meter_t circumference) override |
| SmartMotorControllerConfig & | GetConfig () override |
| void * | GetMotorController () override |
| void * | GetMotorControllerConfig () override |
| void | SetSimSupplier (std::shared_ptr< SimSupplier > supplier) override |
| void | SetVelocity (wpi::units::meters_per_second_t velocity, wpi::units::newton_t feedforwardForce) |
| Public Member Functions inherited from yams::motorcontrollers::SmartMotorController | |
| virtual | ~SmartMotorController () |
| SimSupplier * | GetSimSupplier () const |
| void | SetVelocity (wpi::units::meters_per_second_t velocity, wpi::units::newton_t feedforwardForce) |
| wpi::math::DCMotor | GetMechanismDCMotor () |
| void | SetMechanismSimSupplier (std::shared_ptr< SimSupplier > supplier) |
| double | GetMechanismDutyCycle (double dutyCycle) |
| wpi::units::second_t | GetClosedLoopControllerPeriod () const |
| virtual std::optional< wpi::units::second_t > | GetVelocityMeasurementDelay () const |
| void | StartClosedLoopController () |
| void | StopClosedLoopController () |
| bool | IsClosedLoopControllerStopped () const |
| math::LQRController * | GetLQRController () |
| math::ADRCController * | GetADRCController () |
| void | IterateClosedLoopController () |
| void | SetupTelemetry (std::shared_ptr< wpi::nt::NetworkTable > dataTable, std::shared_ptr< wpi::nt::NetworkTable > tuningTable) |
| void | SetupTelemetry () |
| void | SetupLiveTuning () |
| void | UpdateTelemetry () |
| bool | TuningEnabled () const |
| void | ApplyTuningValues () |
| void | StopLiveTuning () |
| const std::vector< SmartMotorController * > & | GetLooselyCoupledFollowers () const |
| void | AddCloseHook (std::function< void()> hook) |
| SmartMotorController & | WithTelemetry (telemetry::SmartMotorControllerTelemetryConfig config) |
| virtual telemetry::UnsupportedTelemetryFields | GetUnsupportedTelemetryFields () |
| ClosedLoopControllerSlot | GetClosedLoopControllerSlot () const |
| std::optional< wpi::units::turn_t > | GetMechanismPositionSetpoint () const |
| std::optional< wpi::units::turns_per_second_t > | GetMechanismSetpointVelocity () const |
| std::optional< wpi::units::meter_t > | GetMeasurementPositionSetpoint () const |
| std::optional< wpi::units::meters_per_second_t > | GetMeasurementSetpointVelocity () const |
| std::optional< wpi::units::newton_t > | GetSetpointFeedforwardForce () const |
| std::string | GetName () const |
| bool | IsMotor (const wpi::math::DCMotor &a, const wpi::math::DCMotor &b) const |
| void | CheckConfigSafety () |
| void | Close () |
Additional Inherited Members | |
| Public Types inherited from yams::motorcontrollers::SmartMotorController | |
| using | ClosedLoopControllerSlot = SmartMotorControllerConfig::ClosedLoopControllerSlot |
| using | MotorMode = SmartMotorControllerConfig::MotorMode |
| using | ControlMode = SmartMotorControllerConfig::ControlMode |
| Protected Member Functions inherited from yams::motorcontrollers::SmartMotorController | |
| SmartMotorController () | |
| void | LoadLooselyCoupledFollowers () |
| void | Follow (SmartMotorController &leader, bool inverted) |
| double | CalculateSimDutyCycle (double dutyCycle) |
| void | ConfigureSoftwarePID (const SmartMotorControllerConfig &config) |
| void | ForwardPositionToFollowers (wpi::units::turn_t pos) |
| void | ForwardPositionToFollowers (wpi::units::meter_t dist) |
| void | ForwardVelocityToFollowers (wpi::units::turns_per_second_t vel) |
| void | ForwardVelocityToFollowers (wpi::units::meters_per_second_t vel) |
| bool | UsesSystemCoreController () const |
| void | ApplyADRCConfig (const SmartMotorControllerConfig &config) |
| const void * | BatterySimKey () const |
| Protected Attributes inherited from yams::motorcontrollers::SmartMotorController | |
| SmartMotorControllerConfig * | m_config {nullptr} |
| ClosedLoopControllerSlot | m_slot {ClosedLoopControllerSlot::SLOT_0} |
| std::shared_ptr< SimSupplier > | m_simSupplier |
| std::vector< SmartMotorController * > | m_looseFollowers |
| bool | m_iteratedByLeader {false} |
| bool | m_simulatesMechanism {false} |
| std::optional< wpi::math::PIDController > | m_pid |
| std::optional< math::LQRController > | m_lqr |
| std::optional< math::ADRCController > | m_adrc |
| std::optional< wpi::math::TrapezoidProfile< wpi::units::turns >::State > | m_trapState |
| std::optional< wpi::math::ExponentialProfile< wpi::units::turns, wpi::units::volts >::State > | m_expoState |
| std::optional< wpi::math::TrapezoidProfile< wpi::units::meters >::State > | m_linearTrapState |
| std::optional< wpi::math::ExponentialProfile< wpi::units::meters, wpi::units::volts >::State > | m_linearExpoState |
| std::optional< wpi::units::turn_t > | m_lastClosedLoopMechanismPosition |
| std::optional< double > | m_lastClosedLoopVoltage |
| std::optional< wpi::units::turn_t > | m_setpointPosition |
| std::optional< wpi::units::turns_per_second_t > | m_setpointVelocity |
| std::optional< wpi::units::newton_t > | m_setpointFeedforwardForce |
| std::vector< std::function< void()> > | m_closeHooks |
| std::unique_ptr< wpi::Notifier > | m_closedLoopControllerThread |
| bool | m_closedLoopControllerRunning {false} |
| std::shared_ptr< wpi::nt::NetworkTable > | m_parentTable |
| std::shared_ptr< wpi::nt::NetworkTable > | m_telemetryTable |
| std::shared_ptr< wpi::nt::NetworkTable > | m_tuningTable |
| telemetry::SmartMotorControllerTelemetry | m_telemetry |
| telemetry::SmartMotorControllerTelemetryConfig | m_telemetryConfig |
| bool | m_telemetryConfigExplicit {false} |
| std::shared_ptr< telemetry::SmartMotorControllerTelemetryConfig > | m_specifiedTelemetryConfig |
| bool | m_liveTuningRegistered {false} |
| bool | m_closed {false} |
| Static Protected Attributes inherited from yams::motorcontrollers::SmartMotorController | |
| static constexpr double | kClosedLoopRampFullScaleVolts = 12.0 |
Detailed Description
SmartMotorController implementation for The Thrifty Bot's Thrifty Nova, using ThriftyLib 2027.
The closed loop runs on the Nova: its voltage position and velocity loops with the slot's PID gains, and, with a trapezoidal profile, its motion profile, with the motion profile slot's kS, kV, kA and kG and a constant or cosine gravity. The Nova applies a feedforward only with a motion profile, so a feedforward needs a trapezoidal profile. An LQR, an exponential profile and a velocity trapezoidal profile run on the SystemCore instead, and command the Nova with voltage. The Nova has two closed loop slots, SLOT_0 and SLOT_1. ThriftyLib's simulation ignores the Nova's closed loop, so in simulation a NovaSimSupplier runs it.
Supported external encoders (WithExternalEncoder):
- thrifty::Motor::FeedbackSensorType::ABS: an absolute encoder on the Nova's data port. Its type comes from the vendor config, such as thrifty::NovaConfig::AbsoluteEncoderType(thrifty::Motor::AbsoluteEncoderType::REV_ENCODER).
- thrifty::Motor::FeedbackSensorType::QUAD: a quadrature encoder on the Nova's data port. Its type comes from the vendor config, such as thrifty::NovaConfig::QuadratureEncoderType(thrifty::Motor::QuadratureEncoderType::Custom(2048)).
- thrifty::CanEncoder*: a Thrifty CAN Encoder on the same CAN bus.
An absolute or CAN external encoder reads the continuous wrapping range, or [0, 1) without continuous wrapping; the Nova closes its loop on one over [0, 1) only.
The vendor config, if any, must be a thrifty::NovaConfigBatch; it is applied before the YAMS config, which overrides it.
Example usage (inside a subsystem constructor)
Constructor & Destructor Documentation
◆ NovaWrapper()
| yams::motorcontrollers::local::NovaWrapper::NovaWrapper | ( | thrifty::Nova * | nova, |
| wpi::math::DCMotor | motor, | ||
| SmartMotorControllerConfig * | config ) |
Construct a NovaWrapper around a Thrifty Nova.
- Parameters
-
nova Pointer to the Nova hardware object (must outlive this wrapper). motor DC motor model used for simulation. config Pointer to the SmartMotorControllerConfig (must outlive this wrapper).
◆ ~NovaWrapper()
| yams::motorcontrollers::local::NovaWrapper::~NovaWrapper | ( | ) |
Member Function Documentation
◆ ApplyConfig()
|
overridevirtual |
Apply a SmartMotorControllerConfig to the underlying hardware.
- Parameters
-
config Configuration to apply.
- Returns
- true if the configuration was applied successfully.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetConfig()
|
overridevirtual |
Get a mutable reference to the current configuration.
- Returns
- Reference to the SmartMotorControllerConfig.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetDCMotor()
|
overridevirtual |
Get the DC motor model associated with this controller.
- Returns
- wpi::math::DCMotor model.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetDutyCycle()
|
overridevirtual |
Get the current motor duty cycle.
- Returns
- Duty cycle in [-1, 1].
Implements yams::motorcontrollers::SmartMotorController.
◆ GetExternalEncoderMechanismPosition()
|
overridevirtual |
Get the mechanism position from the external (absolute) encoder (applies the external encoder gearing). Available whether or not the external encoder is used for feedback.
- Returns
- Mechanism position in turns from the external encoder, or empty if none is attached.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetExternalEncoderMechanismVelocity()
|
overridevirtual |
Get the mechanism velocity from the external (absolute) encoder (applies the external encoder gearing). Available whether or not the external encoder is used for feedback.
- Returns
- Mechanism velocity in turns per second from the external encoder, or empty if none is attached.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetMeasurementAcceleration()
|
overridevirtual |
Get the linear measurement acceleration.
- Returns
- Linear acceleration in meters per second squared.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetMeasurementPosition()
|
overridevirtual |
Get the linear measurement position (applies circumference conversion).
- Returns
- Linear position in meters.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetMeasurementVelocity()
|
overridevirtual |
Get the linear measurement velocity (applies circumference conversion).
- Returns
- Linear velocity in meters per second.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetMechanismAcceleration()
|
overridevirtual |
Get the mechanism acceleration (derived from velocity).
- Returns
- Mechanism acceleration in turns per second squared.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetMechanismPosition()
|
overridevirtual |
Get the mechanism position (applies gearing). Uses the external (absolute) encoder when one is configured with SmartMotorControllerConfig::WithUseExternalFeedbackEncoder(), otherwise the relative encoder. Use GetRelativeMechanismPosition() to only read the relative encoder.
- Returns
- Mechanism position in turns.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetMechanismVelocity()
|
overridevirtual |
Get the mechanism velocity (applies gearing). Uses the external (absolute) encoder when one is configured with SmartMotorControllerConfig::WithUseExternalFeedbackEncoder(), otherwise the relative encoder. Use GetRelativeMechanismVelocity() to only read the relative encoder.
- Returns
- Mechanism velocity in turns per second.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetMotorController()
|
overridevirtual |
Get a raw pointer to the underlying Nova.
- Returns
- Pointer to the thrifty::Nova instance.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetMotorControllerConfig()
|
overridevirtual |
Get a raw pointer to the vendor config given to WithVendorConfig().
ThriftyLib configs are write-only actions; read the Nova's configuration back from thrifty::Nova::Status().
- Returns
- Pointer to the thrifty::NovaConfigBatch, or nullptr without one.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetRelativeMechanismPosition()
|
overridevirtual |
Get the mechanism position from the relative encoder in the motor (applies gearing). Never uses the external (absolute) encoder.
- Returns
- Mechanism position in turns from the relative encoder.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetRelativeMechanismVelocity()
|
overridevirtual |
Get the mechanism velocity from the relative encoder in the motor (applies gearing). Never uses the external (absolute) encoder.
- Returns
- Mechanism velocity in turns per second from the relative encoder.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetRotorPosition()
|
overridevirtual |
Get the raw rotor position (no gearing applied).
- Returns
- Rotor position in turns.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetRotorVelocity()
|
overridevirtual |
Get the raw rotor velocity (no gearing applied).
- Returns
- Rotor velocity in turns per second.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetStatorCurrent()
|
overridevirtual |
Get the stator (output) current draw.
- Returns
- Stator current.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetSupplyCurrent()
|
overridevirtual |
Get the supply (input) current draw.
- Returns
- Supply current, or empty if not supported by the hardware.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetTemperature()
|
overridevirtual |
Get the motor controller temperature.
- Returns
- Temperature in degrees Celsius.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetVoltage()
|
overridevirtual |
Get the voltage currently applied to the motor.
- Returns
- Applied voltage.
Implements yams::motorcontrollers::SmartMotorController.
◆ SeedRelativeEncoder()
|
overridevirtual |
Seed the relative encoder from the absolute sensor position (one-shot on startup).
Implements yams::motorcontrollers::SmartMotorController.
◆ SetClosedLoopRampRate()
|
overridevirtual |
The Nova has one ramp rate, for both open and closed loop control.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetClosedLoopSlot()
|
overridevirtual |
Select the active closed-loop gain slot.
- Parameters
-
slot Gain slot to activate.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetDutyCycle()
|
overridevirtual |
Command a duty-cycle output to the motor.
- Parameters
-
dutyCycle Normalized duty cycle in [-1, 1].
Implements yams::motorcontrollers::SmartMotorController.
◆ SetEncoderInverted()
|
overridevirtual |
The Nova's internal encoder cannot be inverted; always throws std::runtime_error.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetEncoderPosition() [1/2]
|
overridevirtual |
Write a linear distance into the encoder (seeds the position).
- Parameters
-
distance Linear distance to write.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetEncoderPosition() [2/2]
|
overridevirtual |
Write a mechanism angle into the encoder (seeds the position).
- Parameters
-
angle Mechanism angle to write.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetEncoderVelocity() [1/2]
|
overridevirtual |
Linear version of SetEncoderVelocity(turns_per_second_t); throws without a mechanism circumference.
- Parameters
-
velocity Mechanism linear velocity.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetEncoderVelocity() [2/2]
|
overridevirtual |
Set the simulated mechanism velocity. Throws std::runtime_error outside of simulation, since Thrifty Novas do not support setting the encoder velocity.
- Parameters
-
velocity Mechanism velocity.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetExponentialProfile()
|
overridevirtual |
Update the exponential profile. Missing values keep the configured ones.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetFeedback()
|
overridevirtual |
Set all three PID feedback gains at once (live update).
- Parameters
-
kP Proportional gain. kI Integral gain. kD Derivative gain.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetFeedforward()
|
overridevirtual |
Set all four feedforward gains at once (live update).
- Parameters
-
kS Static friction voltage. kV Velocity feedforward coefficient. kA Acceleration feedforward coefficient. kG Gravity feedforward coefficient.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetKa()
|
overridevirtual |
Set the acceleration feedforward coefficient (live update).
- Parameters
-
kA Acceleration feedforward coefficient.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetKd()
|
overridevirtual |
Set the derivative gain (live update).
- Parameters
-
kD Derivative gain.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetKg()
|
overridevirtual |
Set the gravity feedforward coefficient (live update).
- Parameters
-
kG Gravity feedforward coefficient.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetKi()
|
overridevirtual |
Set the integral gain (live update).
- Parameters
-
kI Integral gain.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetKp()
|
overridevirtual |
Set the proportional gain (live update).
- Parameters
-
kP Proportional gain.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetKs()
|
overridevirtual |
Set the static friction feedforward (live update).
- Parameters
-
kS Static friction voltage.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetKv()
|
overridevirtual |
Set the velocity feedforward coefficient (live update).
- Parameters
-
kV Velocity feedforward coefficient.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetMeasurementLowerLimit()
|
overridevirtual |
Set the lower linear soft limit for the measurement.
- Parameters
-
lowerLimit Lower distance limit.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetMeasurementUpperLimit()
|
overridevirtual |
Set the upper linear soft limit for the measurement.
- Parameters
-
upperLimit Upper distance limit.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetMechanismCircumference()
|
overridevirtual |
Update the mechanism circumference used for linear position/velocity conversions.
The base implementation updates the config; wrappers override it to also reconfigure the hardware.
- Parameters
-
circumference New mechanism circumference.
Reimplemented from yams::motorcontrollers::SmartMotorController.
◆ SetMechanismGearing()
|
overridevirtual |
Update the mechanism gearing and rebuild the simulated motor, which depends on it.
- Parameters
-
gearing New mechanism gearing.
Reimplemented from yams::motorcontrollers::SmartMotorController.
◆ SetMechanismLimits()
|
overridevirtual |
Set both angular soft limits for the mechanism.
- Parameters
-
lower Lower angle limit. upper Upper angle limit.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetMechanismLimitsEnabled()
|
overridevirtual |
The closed loop controller on the SystemCore enforces the mechanism limits.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetMechanismLowerLimit()
|
overridevirtual |
Set the lower angular soft limit for the mechanism.
- Parameters
-
lowerLimit Lower angle limit.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetMechanismUpperLimit()
|
overridevirtual |
Set the upper angular soft limit for the mechanism.
- Parameters
-
upperLimit Upper angle limit.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetMotionProfileMaxAcceleration() [1/2]
|
overridevirtual |
Set the maximum linear acceleration for the motion profile.
- Parameters
-
maxAcc Maximum linear acceleration.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetMotionProfileMaxAcceleration() [2/2]
|
overridevirtual |
Set the maximum angular acceleration for the motion profile.
- Parameters
-
maxAcc Maximum mechanism angular acceleration.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetMotionProfileMaxJerk()
|
overridevirtual |
Set the maximum jerk of a velocity trapezoidal profile (its acceleration constraint). Has no effect on position profiles.
- Parameters
-
maxJerk Maximum angular jerk.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetMotionProfileMaxVelocity() [1/2]
|
overridevirtual |
Set the maximum linear velocity for the motion profile.
- Parameters
-
maxVelocity Maximum linear velocity.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetMotionProfileMaxVelocity() [2/2]
|
overridevirtual |
Set the maximum angular velocity for the motion profile.
- Parameters
-
maxVelocity Maximum mechanism angular velocity.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetMotorInverted()
|
overridevirtual |
Set the motor output direction.
- Parameters
-
inverted true to invert the motor direction.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetOpenLoopRampRate()
|
overridevirtual |
The Nova has one ramp rate, for both open and closed loop control.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetPosition() [1/2]
|
overridevirtual |
Command a linear measurement position setpoint (closed-loop).
- Parameters
-
distance Target linear distance.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetPosition() [2/2]
|
overridevirtual |
Command a mechanism angle position setpoint (closed-loop).
- Parameters
-
angle Target mechanism angle.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetSimSupplier()
|
overridevirtual |
Attach the mechanism's SimSupplier, driven by a simulated Nova, which runs the Nova's closed loop as ThriftyLib's simulation does not.
- Parameters
-
supplier Mechanism's SimSupplier, or nullptr to detach.
Reimplemented from yams::motorcontrollers::SmartMotorController.
◆ SetStatorCurrentLimit()
|
overridevirtual |
Set the stator (output) current limit.
- Parameters
-
currentLimit Maximum stator current.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetSupplyCurrentLimit()
|
overridevirtual |
Set the supply (input) current limit.
- Parameters
-
currentLimit Maximum supply current.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetupSimulation()
|
overridevirtual |
Initialize the DCMotorSim used for simulation.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetVelocity() [1/4]
|
overridevirtual |
Command a linear measurement velocity setpoint (closed-loop).
- Parameters
-
velocity Target linear velocity.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetVelocity() [2/4]
| void yams::motorcontrollers::SmartMotorController::SetVelocity | ( | wpi::units::meters_per_second_t | velocity, |
| wpi::units::newton_t | feedforwardForce ) |
Command a linear velocity setpoint with an additional feedforward force applied on top.
Throws SmartMotorControllerConfigurationException if the mechanism circumference is not configured.
- Parameters
-
velocity Target linear velocity. feedforwardForce Additional feedforward force at the mechanism.
◆ SetVelocity() [3/4]
|
overridevirtual |
Command a mechanism angular velocity setpoint (closed-loop).
- Parameters
-
velocity Target mechanism angular velocity.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetVelocity() [4/4]
|
overridevirtual |
Command a velocity setpoint with an additional feedforward force, added by the SystemCore closed loop.
- Parameters
-
velocity Target mechanism angular velocity. feedforwardForce Additional feedforward force at the mechanism.
Reimplemented from yams::motorcontrollers::SmartMotorController.
◆ SetVoltage()
|
overridevirtual |
Command a voltage output to the motor.
- Parameters
-
voltage Voltage to apply.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetZeroPower()
|
overridevirtual |
Set the idle (neutral) mode of the motor.
- Parameters
-
mode COAST or BRAKE.
Implements yams::motorcontrollers::SmartMotorController.
◆ SimIterate()
|
overridevirtual |
Advance the motor simulation by one loop iteration. Each motor controller's SimIterate() calls this last, with SmartMotorController::SimIterate(): it iterates the loosely coupled followers reading this motor controller's mechanism's simulation, which a mechanism steps right before. Each follower's iterates its own.
Reimplemented from yams::motorcontrollers::SmartMotorController.
◆ SynchronizeRelativeEncoder()
|
overridevirtual |
Periodically re-synchronize the relative encoder to the absolute sensor.
Implements yams::motorcontrollers::SmartMotorController.
The documentation for this class was generated from the following file:
- /home/runner/work/YAMS/YAMS/yams/cpp/include/yams/motorcontrollers/local/NovaWrapper.hpp
