#include <TalonFXSWrapper.hpp>
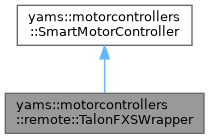
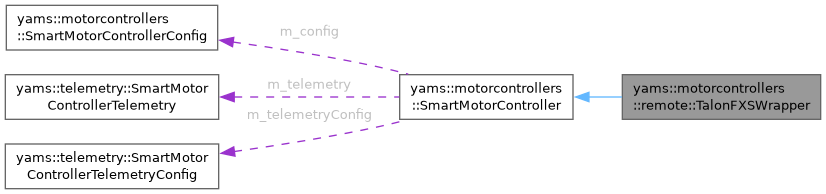
Public Types | |
| enum class | MotorArrangement { Minion , NEO , NEO550 , NEOVortex , Brushed_2Wire , Brushed_3Wire } |
| Public Types inherited from yams::motorcontrollers::SmartMotorController | |
| using | ClosedLoopControllerSlot = SmartMotorControllerConfig::ClosedLoopControllerSlot |
| using | MotorMode = SmartMotorControllerConfig::MotorMode |
| using | ControlMode = SmartMotorControllerConfig::ControlMode |
Public Member Functions | |
| TalonFXSWrapper (ctre::phoenix6::hardware::TalonFXS *talon, wpi::math::DCMotor dcMotor, SmartMotorControllerConfig *config) | |
| TalonFXSWrapper (ctre::phoenix6::hardware::TalonFXS *talon, wpi::math::DCMotor dcMotor, MotorArrangement arrangement, SmartMotorControllerConfig *config) | |
| ~TalonFXSWrapper () | |
| TalonFXSWrapper & | EnableFOC () |
| TalonFXSWrapper & | DisableFOC () |
| bool | UseCANdiPWM1 () const |
| bool | UseCANdiPWM2 () const |
| void | SetUpdateFrequency (wpi::units::hertz_t frequency) |
| ctre::phoenix::StatusCode | ForceConfigApply () |
| telemetry::UnsupportedTelemetryFields | GetUnsupportedTelemetryFields () override |
| bool | ApplyConfig (const SmartMotorControllerConfig &config) override |
| void | SetupSimulation () override |
| void | SimIterate () override |
| void | SeedRelativeEncoder () override |
| void | SynchronizeRelativeEncoder () override |
| void | SetDutyCycle (double dutyCycle) override |
| double | GetDutyCycle () override |
| void | SetVoltage (wpi::units::volt_t voltage) override |
| wpi::units::volt_t | GetVoltage () override |
| std::optional< wpi::units::second_t > | GetVelocityMeasurementDelay () const override |
| void | SetPosition (wpi::units::turn_t angle) override |
| void | SetPosition (wpi::units::meter_t distance) override |
| void | SetVelocity (wpi::units::turns_per_second_t velocity) override |
| void | SetVelocity (wpi::units::meters_per_second_t velocity) override |
| void | SetVelocity (wpi::units::turns_per_second_t velocity, wpi::units::newton_t feedforwardForce) override |
| void | SetEncoderPosition (wpi::units::turn_t angle) override |
| void | SetEncoderPosition (wpi::units::meter_t distance) override |
| void | SetEncoderVelocity (wpi::units::turns_per_second_t velocity) override |
| void | SetEncoderVelocity (wpi::units::meters_per_second_t velocity) override |
| wpi::units::turn_t | GetMechanismPosition () override |
| wpi::units::turns_per_second_t | GetMechanismVelocity () override |
| wpi::units::turn_t | GetRelativeMechanismPosition () override |
| wpi::units::turns_per_second_t | GetRelativeMechanismVelocity () override |
| wpi::units::turns_per_second_squared_t | GetMechanismAcceleration () override |
| wpi::units::turn_t | GetRotorPosition () override |
| wpi::units::turns_per_second_t | GetRotorVelocity () override |
| wpi::units::meter_t | GetMeasurementPosition () override |
| wpi::units::meters_per_second_t | GetMeasurementVelocity () override |
| wpi::units::meters_per_second_squared_t | GetMeasurementAcceleration () override |
| std::optional< wpi::units::turn_t > | GetExternalEncoderMechanismPosition () override |
| std::optional< wpi::units::turns_per_second_t > | GetExternalEncoderMechanismVelocity () override |
| std::optional< wpi::units::ampere_t > | GetSupplyCurrent () override |
| wpi::units::ampere_t | GetStatorCurrent () override |
| wpi::units::celsius_t | GetTemperature () override |
| wpi::math::DCMotor | GetDCMotor () override |
| void | SetZeroPower (MotorMode mode) override |
| void | SetMotorInverted (bool inverted) override |
| void | SetEncoderInverted (bool inverted) override |
| void | SetKp (double kP) override |
| void | SetKi (double kI) override |
| void | SetKd (double kD) override |
| void | SetFeedback (double kP, double kI, double kD) override |
| void | SetKs (double kS) override |
| void | SetKv (double kV) override |
| void | SetKa (double kA) override |
| void | SetKg (double kG) override |
| void | SetFeedforward (double kS, double kV, double kA, double kG) override |
| void | SetStatorCurrentLimit (wpi::units::ampere_t currentLimit) override |
| void | SetSupplyCurrentLimit (wpi::units::ampere_t currentLimit) override |
| void | SetClosedLoopRampRate (wpi::units::second_t rampRate) override |
| void | SetOpenLoopRampRate (wpi::units::second_t rampRate) override |
| void | SetMechanismUpperLimit (wpi::units::turn_t upperLimit) override |
| void | SetMechanismLowerLimit (wpi::units::turn_t lowerLimit) override |
| void | SetMechanismLimits (wpi::units::turn_t lower, wpi::units::turn_t upper) override |
| void | SetMechanismLimitsEnabled (bool enabled) override |
| void | SetMeasurementUpperLimit (wpi::units::meter_t upperLimit) override |
| void | SetMeasurementLowerLimit (wpi::units::meter_t lowerLimit) override |
| void | SetMotionProfileMaxVelocity (wpi::units::turns_per_second_t maxVelocity) override |
| void | SetMotionProfileMaxVelocity (wpi::units::meters_per_second_t maxVelocity) override |
| void | SetMotionProfileMaxAcceleration (wpi::units::turns_per_second_squared_t maxAcc) override |
| void | SetMotionProfileMaxAcceleration (wpi::units::meters_per_second_squared_t maxAcc) override |
| void | SetMotionProfileMaxJerk (wpi::units::angular_jerk::turns_per_second_cubed_t maxJerk) override |
| void | SetExponentialProfile (std::optional< double > kV, std::optional< double > kA, std::optional< wpi::units::volt_t > maxInput) override |
| void | SetClosedLoopSlot (ClosedLoopControllerSlot slot) override |
| void | SetMechanismGearing (const gearing::MechanismGearing &gearing) override |
| void | SetMechanismCircumference (wpi::units::meter_t circumference) override |
| SmartMotorControllerConfig & | GetConfig () override |
| void * | GetMotorController () override |
| void * | GetMotorControllerConfig () override |
| void | SetVelocity (wpi::units::meters_per_second_t velocity, wpi::units::newton_t feedforwardForce) |
| Public Member Functions inherited from yams::motorcontrollers::SmartMotorController | |
| virtual | ~SmartMotorController () |
| virtual void | SetSimSupplier (std::shared_ptr< SimSupplier > supplier) |
| SimSupplier * | GetSimSupplier () const |
| void | SetVelocity (wpi::units::meters_per_second_t velocity, wpi::units::newton_t feedforwardForce) |
| wpi::math::DCMotor | GetMechanismDCMotor () |
| void | SetMechanismSimSupplier (std::shared_ptr< SimSupplier > supplier) |
| double | GetMechanismDutyCycle (double dutyCycle) |
| wpi::units::second_t | GetClosedLoopControllerPeriod () const |
| void | StartClosedLoopController () |
| void | StopClosedLoopController () |
| bool | IsClosedLoopControllerStopped () const |
| math::LQRController * | GetLQRController () |
| math::ADRCController * | GetADRCController () |
| void | IterateClosedLoopController () |
| void | SetupTelemetry (std::shared_ptr< wpi::nt::NetworkTable > dataTable, std::shared_ptr< wpi::nt::NetworkTable > tuningTable) |
| void | SetupTelemetry () |
| void | SetupLiveTuning () |
| void | UpdateTelemetry () |
| bool | TuningEnabled () const |
| void | ApplyTuningValues () |
| void | StopLiveTuning () |
| const std::vector< SmartMotorController * > & | GetLooselyCoupledFollowers () const |
| void | AddCloseHook (std::function< void()> hook) |
| SmartMotorController & | WithTelemetry (telemetry::SmartMotorControllerTelemetryConfig config) |
| ClosedLoopControllerSlot | GetClosedLoopControllerSlot () const |
| std::optional< wpi::units::turn_t > | GetMechanismPositionSetpoint () const |
| std::optional< wpi::units::turns_per_second_t > | GetMechanismSetpointVelocity () const |
| std::optional< wpi::units::meter_t > | GetMeasurementPositionSetpoint () const |
| std::optional< wpi::units::meters_per_second_t > | GetMeasurementSetpointVelocity () const |
| std::optional< wpi::units::newton_t > | GetSetpointFeedforwardForce () const |
| std::string | GetName () const |
| bool | IsMotor (const wpi::math::DCMotor &a, const wpi::math::DCMotor &b) const |
| void | CheckConfigSafety () |
| void | Close () |
Additional Inherited Members | |
| Protected Member Functions inherited from yams::motorcontrollers::SmartMotorController | |
| SmartMotorController () | |
| void | LoadLooselyCoupledFollowers () |
| void | Follow (SmartMotorController &leader, bool inverted) |
| double | CalculateSimDutyCycle (double dutyCycle) |
| void | ConfigureSoftwarePID (const SmartMotorControllerConfig &config) |
| void | ForwardPositionToFollowers (wpi::units::turn_t pos) |
| void | ForwardPositionToFollowers (wpi::units::meter_t dist) |
| void | ForwardVelocityToFollowers (wpi::units::turns_per_second_t vel) |
| void | ForwardVelocityToFollowers (wpi::units::meters_per_second_t vel) |
| bool | UsesSystemCoreController () const |
| void | ApplyADRCConfig (const SmartMotorControllerConfig &config) |
| const void * | BatterySimKey () const |
| Protected Attributes inherited from yams::motorcontrollers::SmartMotorController | |
| SmartMotorControllerConfig * | m_config {nullptr} |
| ClosedLoopControllerSlot | m_slot {ClosedLoopControllerSlot::SLOT_0} |
| std::shared_ptr< SimSupplier > | m_simSupplier |
| std::vector< SmartMotorController * > | m_looseFollowers |
| bool | m_iteratedByLeader {false} |
| bool | m_simulatesMechanism {false} |
| std::optional< wpi::math::PIDController > | m_pid |
| std::optional< math::LQRController > | m_lqr |
| std::optional< math::ADRCController > | m_adrc |
| std::optional< wpi::math::TrapezoidProfile< wpi::units::turns >::State > | m_trapState |
| std::optional< wpi::math::ExponentialProfile< wpi::units::turns, wpi::units::volts >::State > | m_expoState |
| std::optional< wpi::math::TrapezoidProfile< wpi::units::meters >::State > | m_linearTrapState |
| std::optional< wpi::math::ExponentialProfile< wpi::units::meters, wpi::units::volts >::State > | m_linearExpoState |
| std::optional< wpi::units::turn_t > | m_lastClosedLoopMechanismPosition |
| std::optional< double > | m_lastClosedLoopVoltage |
| std::optional< wpi::units::turn_t > | m_setpointPosition |
| std::optional< wpi::units::turns_per_second_t > | m_setpointVelocity |
| std::optional< wpi::units::newton_t > | m_setpointFeedforwardForce |
| std::vector< std::function< void()> > | m_closeHooks |
| std::unique_ptr< wpi::Notifier > | m_closedLoopControllerThread |
| bool | m_closedLoopControllerRunning {false} |
| std::shared_ptr< wpi::nt::NetworkTable > | m_parentTable |
| std::shared_ptr< wpi::nt::NetworkTable > | m_telemetryTable |
| std::shared_ptr< wpi::nt::NetworkTable > | m_tuningTable |
| telemetry::SmartMotorControllerTelemetry | m_telemetry |
| telemetry::SmartMotorControllerTelemetryConfig | m_telemetryConfig |
| bool | m_telemetryConfigExplicit {false} |
| std::shared_ptr< telemetry::SmartMotorControllerTelemetryConfig > | m_specifiedTelemetryConfig |
| bool | m_liveTuningRegistered {false} |
| bool | m_closed {false} |
| Static Protected Attributes inherited from yams::motorcontrollers::SmartMotorController | |
| static constexpr double | kClosedLoopRampFullScaleVolts = 12.0 |
Detailed Description
SmartMotorController implementation for the CTRE TalonFXS motor controller (Phoenix 6).
The TalonFXS supports third-party brushed and brushless motors (e.g. REV NEO, Minion). Wraps a TalonFXS hardware object and exposes the full SmartMotorController interface including MotionMagic profiles, CANcoder/CANdi synchronization, and simulation support.
Example usage (inside a subsystem constructor)
Member Enumeration Documentation
◆ MotorArrangement
|
strong |
Constructor & Destructor Documentation
◆ TalonFXSWrapper() [1/2]
| yams::motorcontrollers::remote::TalonFXSWrapper::TalonFXSWrapper | ( | ctre::phoenix6::hardware::TalonFXS * | talon, |
| wpi::math::DCMotor | dcMotor, | ||
| SmartMotorControllerConfig * | config ) |
Construct a TalonFXSWrapper for a brushless motor recognised from dcMotor (Minion, NEO, NEO 550 or NEO Vortex); throws std::invalid_argument for other motors.
- Parameters
-
talon TalonFXS hardware object (must outlive this wrapper). dcMotor DC motor model; selects the motor arrangement and is used for simulation. config Initial SmartMotorControllerConfig to apply.
◆ TalonFXSWrapper() [2/2]
| yams::motorcontrollers::remote::TalonFXSWrapper::TalonFXSWrapper | ( | ctre::phoenix6::hardware::TalonFXS * | talon, |
| wpi::math::DCMotor | dcMotor, | ||
| MotorArrangement | arrangement, | ||
| SmartMotorControllerConfig * | config ) |
Construct a TalonFXSWrapper.
The arrangement sets the TalonFXS commutation (MotorArrangement, and advanced hall support for a Minion). Throws SmartMotorControllerConfigurationException (or std::invalid_argument) if ApplyConfig() rejects the config; anything already started is released first.
- Parameters
-
talon TalonFXS hardware object (must outlive this wrapper). dcMotor DC motor model used for simulation. arrangement Motor type connected to the TalonFXS. config Initial SmartMotorControllerConfig to apply.
◆ ~TalonFXSWrapper()
| yams::motorcontrollers::remote::TalonFXSWrapper::~TalonFXSWrapper | ( | ) |
Calls Close() and releases the alerts.
Member Function Documentation
◆ ApplyConfig()
|
overridevirtual |
Apply a SmartMotorControllerConfig to the underlying hardware.
- Parameters
-
config Configuration to apply.
- Returns
- true if the configuration was applied successfully.
Implements yams::motorcontrollers::SmartMotorController.
◆ DisableFOC()
| TalonFXSWrapper & yams::motorcontrollers::remote::TalonFXSWrapper::DisableFOC | ( | ) |
Disable FOC for the position and velocity control requests.
Throws SmartMotorControllerConfigurationException if a request is a TorqueCurrentFOC request.
- Returns
- *this for chaining.
◆ EnableFOC()
| TalonFXSWrapper & yams::motorcontrollers::remote::TalonFXSWrapper::EnableFOC | ( | ) |
Enable FOC for the position and velocity control requests; ignored by unlicensed devices.
Throws SmartMotorControllerConfigurationException if a request is a TorqueCurrentFOC request (set through WithVendorControlRequest), which cannot toggle FOC.
- Returns
- *this for chaining.
◆ ForceConfigApply()
| ctre::phoenix::StatusCode yams::motorcontrollers::remote::TalonFXSWrapper::ForceConfigApply | ( | ) |
Apply the whole TalonFXS configuration, retrying every 10 ms up to 10 times.
- Returns
- Status of the last attempt.
◆ GetConfig()
|
overridevirtual |
Get a mutable reference to the current configuration.
- Returns
- Reference to the SmartMotorControllerConfig.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetDCMotor()
|
overridevirtual |
Get the DC motor model associated with this controller.
- Returns
- wpi::math::DCMotor model.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetDutyCycle()
|
overridevirtual |
Get the current motor duty cycle.
- Returns
- Duty cycle in [-1, 1].
Implements yams::motorcontrollers::SmartMotorController.
◆ GetExternalEncoderMechanismPosition()
|
overridevirtual |
Get the mechanism position from the external (absolute) encoder (applies the external encoder gearing). Available whether or not the external encoder is used for feedback.
- Returns
- Mechanism position in turns from the external encoder, or empty if none is attached.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetExternalEncoderMechanismVelocity()
|
overridevirtual |
Get the mechanism velocity from the external (absolute) encoder (applies the external encoder gearing). Available whether or not the external encoder is used for feedback.
- Returns
- Mechanism velocity in turns per second from the external encoder, or empty if none is attached.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetMeasurementAcceleration()
|
overridevirtual |
Get the linear measurement acceleration.
- Returns
- Linear acceleration in meters per second squared.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetMeasurementPosition()
|
overridevirtual |
Get the linear measurement position (applies circumference conversion).
- Returns
- Linear position in meters.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetMeasurementVelocity()
|
overridevirtual |
Get the linear measurement velocity (applies circumference conversion).
- Returns
- Linear velocity in meters per second.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetMechanismAcceleration()
|
overridevirtual |
Get the mechanism acceleration (derived from velocity).
- Returns
- Mechanism acceleration in turns per second squared.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetMechanismPosition()
|
overridevirtual |
Get the mechanism position (applies gearing). Uses the external (absolute) encoder when one is configured with SmartMotorControllerConfig::WithUseExternalFeedbackEncoder(), otherwise the relative encoder. Use GetRelativeMechanismPosition() to only read the relative encoder.
- Returns
- Mechanism position in turns.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetMechanismVelocity()
|
overridevirtual |
Get the mechanism velocity (applies gearing). Uses the external (absolute) encoder when one is configured with SmartMotorControllerConfig::WithUseExternalFeedbackEncoder(), otherwise the relative encoder. Use GetRelativeMechanismVelocity() to only read the relative encoder.
- Returns
- Mechanism velocity in turns per second.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetMotorController()
|
overridevirtual |
Get a raw pointer to the underlying TalonFXS hardware object.
- Returns
- Pointer to the ctre::phoenix6::hardware::TalonFXS instance.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetMotorControllerConfig()
|
overridevirtual |
Get a raw pointer to the TalonFXSConfiguration used by this wrapper.
- Returns
- Pointer to the ctre::phoenix6::configs::TalonFXSConfiguration instance.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetRelativeMechanismPosition()
|
overridevirtual |
Get the mechanism position from the relative encoder in the motor (applies gearing). Never uses the external (absolute) encoder.
- Returns
- Mechanism position in turns from the relative encoder.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetRelativeMechanismVelocity()
|
overridevirtual |
Get the mechanism velocity from the relative encoder in the motor (applies gearing). Never uses the external (absolute) encoder.
- Returns
- Mechanism velocity in turns per second from the relative encoder.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetRotorPosition()
|
overridevirtual |
Get the raw rotor position (no gearing applied).
- Returns
- Rotor position in turns.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetRotorVelocity()
|
overridevirtual |
Get the raw rotor velocity (no gearing applied).
- Returns
- Rotor velocity in turns per second.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetStatorCurrent()
|
overridevirtual |
Get the stator (output) current draw.
- Returns
- Stator current.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetSupplyCurrent()
|
overridevirtual |
Get the supply (input) current draw.
- Returns
- Supply current, or empty if not supported by the hardware.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetTemperature()
|
overridevirtual |
Get the motor controller temperature.
- Returns
- Temperature in degrees Celsius.
Implements yams::motorcontrollers::SmartMotorController.
◆ GetUnsupportedTelemetryFields()
|
overridevirtual |
Return telemetry fields not supported by this motor controller implementation.
Subclasses override this to disable fields for hardware that lacks certain signals (e.g. SPARK controllers do not expose supply current).
- Returns
- Struct with optional lists of unsupported boolean and double fields.
Reimplemented from yams::motorcontrollers::SmartMotorController.
◆ GetVelocityMeasurementDelay()
|
overridevirtual |
Phoenix 6 filters velocity with a Kalman filter tuned for the least latency, about 1 ms, as WPILib's SysId takes it for its CTRE Phoenix 6 preset. A closed loop run on the SystemCore reads the velocity from its status signal instead, which on average is half the signal's update period older. Phoenix 6 simulates the Talon in its own thread with the same filtering, so the delay is the same in simulation.
Reimplemented from yams::motorcontrollers::SmartMotorController.
◆ GetVoltage()
|
overridevirtual |
Get the voltage currently applied to the motor.
- Returns
- Applied voltage.
Implements yams::motorcontrollers::SmartMotorController.
◆ SeedRelativeEncoder()
|
overridevirtual |
TalonFXS uses an absolute sensor internally; has no effect.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetClosedLoopRampRate()
|
overridevirtual |
Set the closed-loop output ramp rate.
- Parameters
-
rampRate Time to ramp from 0 to full output.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetClosedLoopSlot()
|
overridevirtual |
Select the active closed-loop gain slot and forward it to loosely coupled followers. TalonFXS supports 3 slots (SLOT_0 through SLOT_2); throws std::invalid_argument for SLOT_3.
- Parameters
-
slot Gain slot to activate.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetDutyCycle()
|
overridevirtual |
Command a duty-cycle output to the motor.
- Parameters
-
dutyCycle Normalized duty cycle in [-1, 1].
Implements yams::motorcontrollers::SmartMotorController.
◆ SetEncoderInverted()
|
overridevirtual |
Set the external feedback sensor phase (SensorPhase Opposed when inverted).
Implements yams::motorcontrollers::SmartMotorController.
◆ SetEncoderPosition() [1/2]
|
overridevirtual |
Write a linear distance into the encoder (seeds the position). Converts distance to turns using the configured mechanism circumference.
- Parameters
-
distance Linear distance to write.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetEncoderPosition() [2/2]
|
overridevirtual |
Write a mechanism angle into the encoder (seeds the position).
- Parameters
-
angle Mechanism angle to write.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetEncoderVelocity() [1/2]
|
overridevirtual |
Not applicable to TalonFXS; has no effect.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetEncoderVelocity() [2/2]
|
overridevirtual |
Not applicable to TalonFXS; has no effect.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetExponentialProfile()
|
overridevirtual |
Configure or update the exponential motion profile parameters.
- Parameters
-
kV Optional velocity constant (empty keeps the current value). kA Optional acceleration constant (empty keeps the current value). maxInput Optional maximum voltage input (empty keeps the current value).
Implements yams::motorcontrollers::SmartMotorController.
◆ SetFeedback()
|
overridevirtual |
Set all three PID feedback gains at once (live update).
- Parameters
-
kP Proportional gain. kI Integral gain. kD Derivative gain.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetFeedforward()
|
overridevirtual |
Set all four feedforward gains at once (live update).
- Parameters
-
kS Static friction voltage. kV Velocity feedforward coefficient. kA Acceleration feedforward coefficient. kG Gravity feedforward coefficient.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetKa()
|
overridevirtual |
Set the acceleration feedforward coefficient (live update).
- Parameters
-
kA Acceleration feedforward coefficient.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetKd()
|
overridevirtual |
Set the derivative gain (live update).
- Parameters
-
kD Derivative gain.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetKg()
|
overridevirtual |
Set the gravity feedforward coefficient (live update).
- Parameters
-
kG Gravity feedforward coefficient.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetKi()
|
overridevirtual |
Set the integral gain (live update).
- Parameters
-
kI Integral gain.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetKp()
|
overridevirtual |
Set the proportional gain (live update).
- Parameters
-
kP Proportional gain.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetKs()
|
overridevirtual |
Set the static friction feedforward (live update).
- Parameters
-
kS Static friction voltage.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetKv()
|
overridevirtual |
Set the velocity feedforward coefficient (live update).
- Parameters
-
kV Velocity feedforward coefficient.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetMeasurementLowerLimit()
|
overridevirtual |
Set the lower linear soft limit for the measurement. Converts the lower limit to turns using the configured mechanism circumference.
- Parameters
-
lowerLimit Lower distance limit.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetMeasurementUpperLimit()
|
overridevirtual |
Set the upper linear soft limit for the measurement. Converts the upper limit to turns using the configured mechanism circumference.
- Parameters
-
upperLimit Upper distance limit.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetMechanismCircumference()
|
overridevirtual |
Update the mechanism circumference, rewrite the values converted with it (linear gains and motion profile constraints) and forward it to loosely coupled followers.
- Parameters
-
circumference New mechanism circumference.
Reimplemented from yams::motorcontrollers::SmartMotorController.
◆ SetMechanismGearing()
|
overridevirtual |
Update the mechanism gearing and the TalonFXS sensor ratios that depend on it.
- Parameters
-
gearing New mechanism gearing.
Reimplemented from yams::motorcontrollers::SmartMotorController.
◆ SetMechanismLimits()
|
overridevirtual |
Set both angular soft limits for the mechanism.
- Parameters
-
lower Lower angle limit. upper Upper angle limit.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetMechanismLimitsEnabled()
|
overridevirtual |
Enable or disable the mechanism angular soft limits.
- Parameters
-
enabled true to enforce the limits.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetMechanismLowerLimit()
|
overridevirtual |
Set the lower angular soft limit for the mechanism.
- Parameters
-
lowerLimit Lower angle limit.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetMechanismUpperLimit()
|
overridevirtual |
Set the upper angular soft limit for the mechanism.
- Parameters
-
upperLimit Upper angle limit.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetMotionProfileMaxAcceleration() [1/2]
|
overridevirtual |
Set the maximum linear acceleration for the motion profile. Converts linear acceleration to turns per second squared using the configured mechanism circumference.
- Parameters
-
maxAcc Maximum linear acceleration.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetMotionProfileMaxAcceleration() [2/2]
|
overridevirtual |
◆ SetMotionProfileMaxJerk()
|
overridevirtual |
Set the maximum angular jerk for the motion profile.
- Parameters
-
maxJerk Maximum angular jerk (degrees/s²/s).
Implements yams::motorcontrollers::SmartMotorController.
◆ SetMotionProfileMaxVelocity() [1/2]
|
overridevirtual |
Set the maximum linear velocity for the motion profile. Converts linear velocity to turns per second using the configured mechanism circumference.
- Parameters
-
maxVelocity Maximum linear velocity.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetMotionProfileMaxVelocity() [2/2]
|
overridevirtual |
Set the maximum angular velocity for the motion profile.
- Parameters
-
maxVelocity Maximum mechanism angular velocity.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetMotorInverted()
|
overridevirtual |
Set the motor output direction.
- Parameters
-
inverted true to invert the motor direction.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetOpenLoopRampRate()
|
overridevirtual |
Set the open-loop output ramp rate.
- Parameters
-
rampRate Time to ramp from 0 to full output.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetPosition() [1/2]
|
overridevirtual |
Command a linear measurement position setpoint (closed-loop). Converts distance to turns using the configured mechanism circumference.
- Parameters
-
distance Target linear distance.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetPosition() [2/2]
|
overridevirtual |
Command a mechanism angle position setpoint (closed-loop).
- Parameters
-
angle Target mechanism angle.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetStatorCurrentLimit()
|
overridevirtual |
Set the stator (output) current limit.
- Parameters
-
currentLimit Maximum stator current.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetSupplyCurrentLimit()
|
overridevirtual |
Set the supply (input) current limit.
- Parameters
-
currentLimit Maximum supply current.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetUpdateFrequency()
| void yams::motorcontrollers::remote::TalonFXSWrapper::SetUpdateFrequency | ( | wpi::units::hertz_t | frequency | ) |
Set the update frequency of the status signals this controller reads.
- Parameters
-
frequency Update frequency.
◆ SetupSimulation()
|
overridevirtual |
Initialize the DCMotorSim used for simulation.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetVelocity() [1/4]
|
overridevirtual |
Command a linear measurement velocity setpoint (closed-loop). Converts linear velocity to turns per second using the configured mechanism circumference.
- Parameters
-
velocity Target linear velocity.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetVelocity() [2/4]
| void yams::motorcontrollers::SmartMotorController::SetVelocity | ( | wpi::units::meters_per_second_t | velocity, |
| wpi::units::newton_t | feedforwardForce ) |
Command a linear velocity setpoint with an additional feedforward force applied on top.
Throws SmartMotorControllerConfigurationException if the mechanism circumference is not configured.
- Parameters
-
velocity Target linear velocity. feedforwardForce Additional feedforward force at the mechanism.
◆ SetVelocity() [3/4]
|
overridevirtual |
Command a mechanism angular velocity setpoint (closed-loop).
- Parameters
-
velocity Target mechanism angular velocity.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetVelocity() [4/4]
|
overridevirtual |
Command a velocity setpoint with an additional feedforward force, applied by the TalonFXS as an arbitrary feedforward (duty cycle, volts or TorqueCurrentFOC amps depending on the request). With an LQR the RoboRIO loop adds it instead.
Throws SmartMotorControllerConfigurationException if the mechanism circumference is not set.
- Parameters
-
velocity Target mechanism angular velocity. feedforwardForce Additional feedforward force at the mechanism.
Reimplemented from yams::motorcontrollers::SmartMotorController.
◆ SetVoltage()
|
overridevirtual |
Command a voltage output to the motor.
- Parameters
-
voltage Voltage to apply.
Implements yams::motorcontrollers::SmartMotorController.
◆ SetZeroPower()
|
overridevirtual |
Set the idle (neutral) mode of the motor.
- Parameters
-
mode COAST or BRAKE.
Implements yams::motorcontrollers::SmartMotorController.
◆ SimIterate()
|
overridevirtual |
Advance the motor simulation by one loop iteration. Each motor controller's SimIterate() calls this last, with SmartMotorController::SimIterate(): it iterates the loosely coupled followers reading this motor controller's mechanism's simulation, which a mechanism steps right before. Each follower's iterates its own.
Reimplemented from yams::motorcontrollers::SmartMotorController.
◆ SynchronizeRelativeEncoder()
|
overridevirtual |
The TalonFXS fuses its feedback sources on the device; has no effect.
Implements yams::motorcontrollers::SmartMotorController.
◆ UseCANdiPWM1()
| bool yams::motorcontrollers::remote::TalonFXSWrapper::UseCANdiPWM1 | ( | ) | const |
Whether CANdi PWM1 is the feedback sensor of the configuration being applied.
Throws std::invalid_argument if it is but no CANdi is configured as the external encoder.
- Returns
- true if the feedback sensor source is a CANdi PWM1 source.
◆ UseCANdiPWM2()
| bool yams::motorcontrollers::remote::TalonFXSWrapper::UseCANdiPWM2 | ( | ) | const |
Whether CANdi PWM2 is the feedback sensor of the configuration being applied.
Throws std::invalid_argument if it is but no CANdi is configured as the external encoder.
- Returns
- true if the feedback sensor source is a CANdi PWM2 source.
The documentation for this class was generated from the following file:
- /home/runner/work/YAMS/YAMS/yams/cpp/include/yams/motorcontrollers/remote/TalonFXSWrapper.hpp
