#include <FollowerSimSupplier.hpp>
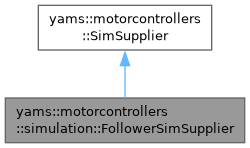
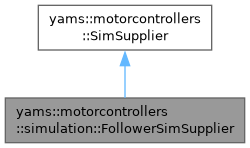
Public Member Functions | |
| FollowerSimSupplier (SmartMotorController &leader, SmartMotorController &follower, bool inverted) | |
| void | UpdateSim () override |
| bool | GetUpdatedSim () override |
| void | FeedUpdateSim () override |
| void | StarveUpdateSim () override |
| bool | IsInputFed () override |
| void | FeedInput () override |
| void | StarveInput () override |
| void | SetMechanismStatorDutyCycle (double) override |
| wpi::units::volt_t | GetMechanismSupplyVoltage () override |
| wpi::units::volt_t | GetMechanismStatorVoltage () override |
| void | SetMechanismStatorVoltage (wpi::units::volt_t) override |
| wpi::units::turn_t | GetMechanismPosition () override |
| void | SetMechanismPosition (wpi::units::turn_t) override |
| wpi::units::turn_t | GetRotorPosition () override |
| wpi::units::turns_per_second_t | GetMechanismVelocity () override |
| void | SetMechanismVelocity (wpi::units::turns_per_second_t) override |
| wpi::units::turns_per_second_t | GetRotorVelocity () override |
| wpi::units::turns_per_second_squared_t | GetMechanismAcceleration () override |
| wpi::units::turns_per_second_squared_t | GetRotorAcceleration () override |
| void | SetRotorPosition (wpi::units::turn_t) override |
| void | SetRotorVelocity (wpi::units::turns_per_second_t) override |
| wpi::units::ampere_t | GetStatorCurrent () override |
| wpi::units::ampere_t | GetSupplyCurrent () override |
| Public Member Functions inherited from yams::motorcontrollers::SimSupplier | |
| virtual | ~SimSupplier ()=default |
Detailed Description
Simulation of a motor whose leader's simulation has its motor too, such as an A301 following another, or a loosely coupled follower of a mechanism's motor controller.
It reads the leader's simulation, with its rotor values from its own gearing and its share of the current, and does not step a simulation of its own. Its current is in the leader's, so BatterySim does not count it again.
Constructor & Destructor Documentation
◆ FollowerSimSupplier()
| yams::motorcontrollers::simulation::FollowerSimSupplier::FollowerSimSupplier | ( | SmartMotorController & | leader, |
| SmartMotorController & | follower, | ||
| bool | inverted ) |
Read the simulation of a leader whose motor model has this follower's motor.
- Parameters
-
leader Motor controller whose simulation has the follower's motor. Must outlive this. follower Motor controller reading it. Must outlive this. inverted Whether the follower is inverted from its leader.
Member Function Documentation
◆ FeedInput()
|
inlineoverridevirtual |
Mark the input as supplied directly for this loop.
Implements yams::motorcontrollers::SimSupplier.
◆ FeedUpdateSim()
|
inlineoverridevirtual |
Mark the simulation as stepped for this loop.
Implements yams::motorcontrollers::SimSupplier.
◆ GetMechanismAcceleration()
|
overridevirtual |
Get the simulated mechanism angular acceleration.
- Returns
- Mechanism acceleration in turns per second squared.
Implements yams::motorcontrollers::SimSupplier.
◆ GetMechanismPosition()
|
overridevirtual |
Get the simulated mechanism position.
- Returns
- Mechanism position in turns.
Implements yams::motorcontrollers::SimSupplier.
◆ GetMechanismStatorVoltage()
|
overridevirtual |
Get the voltage applied to the simulated motor.
- Returns
- Stator voltage in volts.
Implements yams::motorcontrollers::SimSupplier.
◆ GetMechanismSupplyVoltage()
|
overridevirtual |
Get the supply voltage available to the simulated motor controller (bus voltage).
- Returns
- Supply voltage in volts.
Implements yams::motorcontrollers::SimSupplier.
◆ GetMechanismVelocity()
|
overridevirtual |
Get the simulated mechanism velocity.
- Returns
- Mechanism velocity in turns per second.
Implements yams::motorcontrollers::SimSupplier.
◆ GetRotorAcceleration()
|
overridevirtual |
Get the simulated rotor angular acceleration.
- Returns
- Rotor acceleration in turns per second squared.
Implements yams::motorcontrollers::SimSupplier.
◆ GetRotorPosition()
|
overridevirtual |
Get the simulated rotor position.
- Returns
- Rotor position in turns.
Implements yams::motorcontrollers::SimSupplier.
◆ GetRotorVelocity()
|
overridevirtual |
Get the simulated rotor velocity.
- Returns
- Rotor velocity in turns per second.
Implements yams::motorcontrollers::SimSupplier.
◆ GetStatorCurrent()
|
overridevirtual |
Get the simulated stator (motor) current.
- Returns
- Stator current in amperes.
Implements yams::motorcontrollers::SimSupplier.
◆ GetSupplyCurrent()
|
overridevirtual |
Get the simulated supply (battery) current: duty cycle times stator current, filtered by a 0.1 s single-pole IIR filter.
- Returns
- Supply current in amperes.
Implements yams::motorcontrollers::SimSupplier.
◆ GetUpdatedSim()
|
inlineoverridevirtual |
Whether the simulation has already been stepped this loop.
- Returns
- true if UpdateSim() stepped the physics since the last StarveUpdateSim().
Implements yams::motorcontrollers::SimSupplier.
◆ IsInputFed()
|
inlineoverridevirtual |
Whether an input voltage was supplied directly this loop (e.g. from a hardware sim state).
- Returns
- true if the input was fed since the simulation last stepped.
Implements yams::motorcontrollers::SimSupplier.
◆ SetMechanismPosition()
|
inlineoverridevirtual |
Set the simulated mechanism position.
- Parameters
-
angle Mechanism position to inject.
Implements yams::motorcontrollers::SimSupplier.
◆ SetMechanismStatorDutyCycle()
|
inlineoverridevirtual |
Apply a duty cycle of the supply voltage as the motor input (feeds the input).
- Parameters
-
dutyCycle Duty cycle in [-1, 1].
Implements yams::motorcontrollers::SimSupplier.
◆ SetMechanismStatorVoltage()
|
inlineoverridevirtual |
Set the motor input voltage directly, e.g. from a hardware sim state (feeds the input).
- Parameters
-
volts Voltage to apply.
Implements yams::motorcontrollers::SimSupplier.
◆ SetMechanismVelocity()
|
inlineoverridevirtual |
Set the simulated mechanism velocity.
- Parameters
-
velocity Mechanism velocity to inject.
Implements yams::motorcontrollers::SimSupplier.
◆ SetRotorPosition()
|
inlineoverridevirtual |
Set the simulated rotor position.
- Parameters
-
angle Rotor position to inject.
Implements yams::motorcontrollers::SimSupplier.
◆ SetRotorVelocity()
|
inlineoverridevirtual |
Set the simulated rotor velocity.
- Parameters
-
velocity Rotor velocity to inject.
Implements yams::motorcontrollers::SimSupplier.
◆ StarveInput()
|
inlineoverridevirtual |
Clear the input-fed flag so UpdateSim() falls back to the duty-cycle supplier.
Implements yams::motorcontrollers::SimSupplier.
◆ StarveUpdateSim()
|
inlineoverridevirtual |
Clear the stepped flag so the next UpdateSim() steps the physics again.
Implements yams::motorcontrollers::SimSupplier.
◆ UpdateSim()
|
inlineoverridevirtual |
Advance the simulation by one loop iteration.
When the input has not been fed this loop (see FeedInput()), the motor duty cycle times the supply voltage is applied as the input and the battery voltage is updated. The physics are only stepped if the simulation has not already been updated this loop (see GetUpdatedSim()); stepping marks it updated, so a mechanism and its motor controller calling UpdateSim() in the same loop step the physics once.
Implements yams::motorcontrollers::SimSupplier.
The documentation for this class was generated from the following file:
- /home/runner/work/YAMS/YAMS/yams/cpp/include/yams/motorcontrollers/simulation/FollowerSimSupplier.hpp
